Convexity in Several Variables
0.1 Convexity in several variables
NoteSource
This section is adapted from the convexity part of Zhou [1], used under the MIT License (see the license text in Linear Algebra). The source states the first-order test (in one direction) and the second-derivative test for convexity without proof; here both directions of the first-order test are proved, and the second-derivative test is proved from the Taylor theorem of Section 2 in Critical Points and Optimality Conditions. The source defines both concave and strictly concave as “\(-f\) is strictly convex”; here \(f\) is concave when \(-f\) is convex. The source states that an intersection of convex sets is convex and that a maximum of convex functions is convex for any finite number of them; here each is stated for two and the general case follows by induction. These parts of the source are not part of this section:
- its catalogs of convex sets and convex functions, including the positive semidefinite matrices and \(-\log \det\)
- intersections of infinitely many convex sets, and suprema of infinitely many convex functions
- its examples, exercises and figures, including the multivariate normal maximum likelihood example
DefDefinition 1 (Convex set)
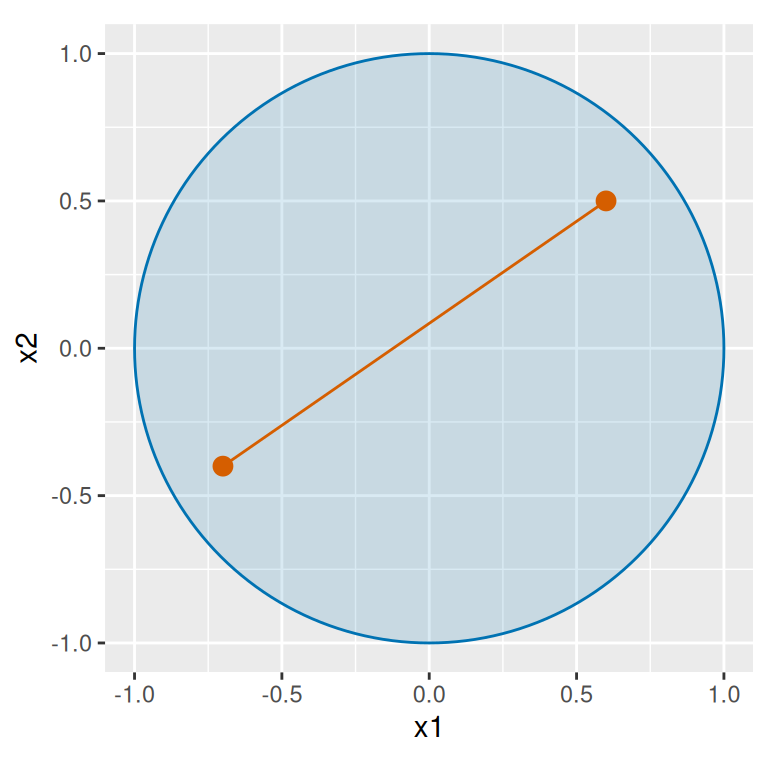
Definition 1 (Convex set) A set \(K \subseteq \mathbb{R}^p\) is convex if [2] for all \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}, \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}\in K\) and all \(t \in [0, 1]\), the point \(t \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}+ (1 - t) \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}\) is in \(K\): \(K\) contains the whole line segment between any two of its points.
ExmExample 1 (Convex sets)
Example 1 (Convex sets)
\(\mathbb{R}^p\) is convex, and so is any set with at most one point.
-
The closed ball (closed ball) \(B = \mathopen{}\left\{\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}: \mathopen{}\left\lVert\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}\right\rVert\mathclose{} \le r\right\}\mathclose{}\) is convex: for \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}, \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}\in B\) and \(t \in [0, 1]\),
\[ \begin{aligned} \mathopen{}\left\lVert t \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}+ (1 - t) \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}\right\rVert\mathclose{} &\le \mathopen{}\left\lVert t \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}\right\rVert\mathclose{} + \mathopen{}\left\lVert(1 - t) \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}\right\rVert\mathclose{} && \text{(triangle inequality)} \\ &= t\,\mathopen{}\left\lVert\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}\right\rVert\mathclose{} + (1 - t)\,\mathopen{}\left\lVert\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}\right\rVert\mathclose{} && \text{(norm of a multiple; } t, 1 - t \ge 0 \text{)} \\ &\le t\,r + (1 - t)\,r && \text{(} \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}, \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}\in B \text{)} \\ &= r. && \text{(arithmetic)} \end{aligned} \]
The first step is the triangle inequality, and the second uses the norm of a multiple.
ExmExample 2 (A set that is not convex)
Example 2 (A set that is not convex) \(K = \mathopen{}\left\{x \in \mathbb{R}: \mathopen{}\left|x\right|\mathclose{} \ge 1\right\}\mathclose{}\) is not convex: \(-1\) and \(1\) are in \(K\), but with \(t = \tfrac{1}{2}\) the point \(\tfrac{1}{2}(-1) + \tfrac{1}{2}(1) = 0\) is not.
Show code
cs_angle_fc <- seq(0, 2 * pi, length.out = 201)
cs_cos_fc <- cos(cs_angle_fc)
cs_sin_fc <- sin(cs_angle_fc)
cs_disk_fc <- tibble::tibble(x1 = cs_cos_fc, x2 = cs_sin_fc)
cs_points_x1_fc <- c(-0.7, 0.6)
cs_points_x2_fc <- c(-0.4, 0.5)
cs_points_fc <- tibble::tibble(x1 = cs_points_x1_fc, x2 = cs_points_x2_fc)
cs_segment_fc <- tibble::tibble(
  x1 = -0.7, x2 = -0.4, x1_end = 0.6, x2_end = 0.5
)
cs_aes_fc <- ggplot2::aes(x1, x2)
cs_seg_aes_fc <- ggplot2::aes(xend = x1_end, yend = x2_end)
ggplot2::ggplot(cs_disk_fc, cs_aes_fc) +
  ggplot2::geom_polygon(fill = "#0072B2", alpha = 0.15, colour = "#0072B2") +
  ggplot2::geom_segment(
    data = cs_segment_fc, mapping = cs_seg_aes_fc, colour = "#D55E00"
  ) +
  ggplot2::geom_point(data = cs_points_fc, colour = "#D55E00", size = 3) +
  ggplot2::coord_fixed() +
  ggplot2::labs(x = "x1", y = "x2")
Show code
import matplotlib.pyplot as plt
import numpy as np

cs_angle_fc = np.linspace(0, 2 * np.pi, 201)
cs_x1_fc = np.array([-0.7, 0.6])
cs_x2_fc = np.array([-0.4, 0.5])
fig, ax = plt.subplots(figsize=(4, 4), layout="constrained")
ax.fill(np.cos(cs_angle_fc), np.sin(cs_angle_fc), color="#0072B2", alpha=0.15)
ax.plot(np.cos(cs_angle_fc), np.sin(cs_angle_fc), color="#0072B2")
ax.plot(cs_x1_fc, cs_x2_fc, "o-", color="#D55E00", markersize=8)
ax.set_aspect("equal")
ax.set_xlabel("x1")
ax.set_ylabel("x2")
plt.show()
DefDefinition 2 (Half-space)
Definition 2 (Half-space) Let \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{a}}\vphantom{a}} \in \mathbb{R}^p\) be a nonzero vector and \(c\) a real number. The set \(\mathopen{}\left\{\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}\in \mathbb{R}^p : \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{a}}\vphantom{a}} \cdot \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}} \ge c\right\}\mathclose{}\) is a (closed) half-space: the points on one side of the boundary \(\mathopen{}\left\{\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}: \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{a}}\vphantom{a}} \cdot \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}} = c\right\}\mathclose{}\), together with the boundary. In \(\mathbb{R}^2\), a half-space is called a half-plane.
ExmExample 3 (The right half-plane)
Example 3 (The right half-plane) With \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{a}}\vphantom{a}} = {(1, 0)}^{\top}\) and \(c = 0\), the half-plane \(\mathopen{}\left\{\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}\in \mathbb{R}^2 : x_1 \ge 0\right\}\mathclose{}\) is the set of points on or to the right of the \(x_2\)-axis. \({(1, 5)}^{\top}\) is in it, since \(1 \ge 0\); \({(0, -3)}^{\top}\) is in it, on the boundary; and \({(-1, 0)}^{\top}\) is not, since \(-1 < 0\).
LemTheorem 1 (An intersection of convex sets is convex)
Theorem 1 (An intersection of convex sets is convex) If \(K_1\) and \(K_2\) are convex subsets of \(\mathbb{R}^p\) (Definition 1), then \(K_1 \cap K_2\) is convex.
ProofProof
Proof. Let \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}, \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}\in K_1 \cap K_2\) and \(t \in [0, 1]\). Then \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}, \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}\in K_1\), so \(t \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}+ (1 - t) \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}\in K_1\), since \(K_1\) is convex; in the same way \(t \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}+ (1 - t) \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}\in K_2\). So \(t \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}+ (1 - t) \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}\in K_1 \cap K_2\).
ExmExample 4 (Intersecting a ball with a half-plane)
Example 4 (Intersecting a ball with a half-plane) The closed unit ball (unit ball) in \(\mathbb{R}^2\) is convex (Example 1), and so is the half-plane (Definition 2) \(\mathopen{}\left\{\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}: x_1 \ge 0\right\}\mathclose{}\): if \(x_1 \ge 0\) and \(y_1 \ge 0\), then \(t x_1 + (1 - t) y_1 \ge 0\) for \(t \in [0, 1]\). By Theorem 1, the closed half-disk \(\mathopen{}\left\{\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}: \mathopen{}\left\lVert\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}\right\rVert\mathclose{} \le 1,\ x_1 \ge 0\right\}\mathclose{}\) is convex. A union need not be convex: \(\mathopen{}\left\{x \in \mathbb{R}: x \le -1\right\}\mathclose{}\) and \(\mathopen{}\left\{x \in \mathbb{R}: x \ge 1\right\}\mathclose{}\) are convex, but their union is the set of Example 2.
DefDefinition 3 (Strictly convex function)
Definition 3 (Strictly convex function) A function \(f : \mathbb{R}^p \to \mathbb{R}\) is strictly convex if \(f(t \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}+ (1 - t) \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}) < t f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}) + (1 - t) f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}})\) for all \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}\ne \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}\) in \(\mathbb{R}^p\) and all \(t \in (0, 1)\).
DefDefinition 4 (Concave function)
Definition 4 (Concave function) A function \(f : \mathbb{R}^p \to \mathbb{R}\) is concave if \(-f\) is convex.
DefDefinition 5 (Strictly concave function)
Definition 5 (Strictly concave function) A function \(f : \mathbb{R}^p \to \mathbb{R}\) is strictly concave if \(-f\) is strictly convex (Definition 3).
ExmExample 5 (Strictly convex, and convex but not strictly)
Example 5 (Strictly convex, and convex but not strictly)
-
\(f(x) = x^2\) is strictly convex:
\[ \begin{aligned} t x^2 + (1 - t) y^2 - (t x + (1 - t) y)^2 &= t x^2 + (1 - t) y^2 - t^2 x^2 - 2 t (1 - t) x y - (1 - t)^2 y^2 && \text{(expand the square)} \\ &= t (1 - t) x^2 - 2 t (1 - t) x y + t (1 - t) y^2 && \text{(} t - t^2 = t (1 - t) \text{, } (1 - t) - (1 - t)^2 = t (1 - t) \text{)} \\ &= t (1 - t) (x - y)^2, && \text{(factor)} \end{aligned} \]
which is positive when \(x \ne y\) and \(t \in (0, 1)\). At \(t \in \mathopen{}\left\{0, 1\right\}\mathclose{}\) or \(x = y\) it is \(0\), so \(x^2\) is also convex.
-
\(f(x) = 2x + 1\) is convex but not strictly convex:
\[ \begin{aligned} f(t x + (1 - t) y) &= 2 t x + 2 (1 - t) y + 1 \\ &= t f(x) + (1 - t) f(y) \end{aligned} \]
for every \(x, y, t\), so the inequality holds, but never strictly. It is also concave.
LemTheorem 2 (The maximum of convex functions is convex)
Theorem 2 (The maximum of convex functions is convex) If \(f_1\) and \(f_2\) are convex functions on \(\mathbb{R}^p\), then \(f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}) \stackrel{\text{def}}{=}\max\mathopen{}\left\{f_1(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}), f_2(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}})\right\}\mathclose{}\) is convex.
ProofProof
Proof. Let \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}, \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}\in \mathbb{R}^p\) and \(t \in [0, 1]\). For \(i = 1, 2\),
\[ \begin{aligned} f_i(t \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}+ (1 - t) \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}) &\le t f_i(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}) + (1 - t) f_i(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}) && \text{(} f_i \text{ is convex)} \\ &\le t f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}) + (1 - t) f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}). && \text{(} f_i \le f \text{, and } t, 1 - t \ge 0 \text{)} \end{aligned} \]
Both \(f_1\) and \(f_2\) at \(t \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}+ (1 - t) \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}\) are at most \(t f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}) + (1 - t) f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}})\), so their maximum \(f(t \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}+ (1 - t) \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}})\) is too.
ExmExample 6 (A maximum is convex; a minimum need not be)
Example 6 (A maximum is convex; a minimum need not be)
\(f_1(x) = x\) is convex, by the computation for \(2x + 1\) in Example 5 with \(2\) and \(1\) replaced by \(1\) and \(0\), and \(f_2(x) = x^2\) is convex by the same example, so \(\max\mathopen{}\left\{x, x^2\right\}\mathclose{}\) is convex by Theorem 2.
-
The minimum of two convex functions need not be convex: \(g(x) = \min\mathopen{}\left\{x^2, (x - 2)^2\right\}\mathclose{}\) has
\[ \begin{aligned} g(0) &= g(2) \\ &= 0, \end{aligned} \]
but at the midpoint
\[ \begin{aligned} g(1) &= \min\mathopen{}\left\{1, 1\right\}\mathclose{} \\ &= 1 \\ &> \tfrac{1}{2} g(0) + \tfrac{1}{2} g(2) \\ &= 0. \end{aligned} \]
Show code
cm_x_fm <- seq(-1, 3, length.out = 201)
cm_levels_fm <- c("max{x, x^2}", "min{x^2, (x - 2)^2}")
cm_max_value_fm <- pmax(cm_x_fm, cm_x_fm^2)
cm_min_value_fm <- pmin(cm_x_fm^2, (cm_x_fm - 2)^2)
cm_max_fm <- tibble::tibble(
  x = cm_x_fm, value = cm_max_value_fm, panel = cm_levels_fm[1]
)
cm_min_fm <- tibble::tibble(
  x = cm_x_fm, value = cm_min_value_fm, panel = cm_levels_fm[2]
)
cm_main_fm <- dplyr::bind_rows(cm_max_fm, cm_min_fm)
cm_main_fm$panel <- factor(cm_main_fm$panel, levels = cm_levels_fm)
cm_square_value_fm <- cm_x_fm^2
cm_line_fm <- tibble::tibble(
  x = cm_x_fm, value = cm_x_fm, panel = cm_levels_fm[1], part = "x"
)
cm_square_fm <- tibble::tibble(
  x = cm_x_fm, value = cm_square_value_fm, panel = cm_levels_fm[1],
  part = "x^2"
)
cm_parts_fm <- dplyr::bind_rows(cm_line_fm, cm_square_fm)
cm_parts_fm$panel <- factor(cm_parts_fm$panel, levels = cm_levels_fm)
cm_chord_fm <- tibble::tibble(
  x = 0, xend = 2, value = 0, panel = cm_levels_fm[2]
)
cm_chord_fm$panel <- factor(cm_chord_fm$panel, levels = cm_levels_fm)
cm_mid_fm <- tibble::tibble(x = 1, value = 1, panel = cm_levels_fm[2])
cm_mid_fm$panel <- factor(cm_mid_fm$panel, levels = cm_levels_fm)
cm_aes_fm <- ggplot2::aes(x, value)
cm_parts_aes_fm <- ggplot2::aes(group = part)
cm_chord_aes_fm <- ggplot2::aes(xend = xend, yend = value)
ggplot2::ggplot(cm_main_fm, cm_aes_fm) +
  ggplot2::geom_line(
    data = cm_parts_fm, mapping = cm_parts_aes_fm,
    colour = "grey60", linewidth = 0.4
  ) +
  ggplot2::geom_line(colour = "#0072B2") +
  ggplot2::geom_segment(
    data = cm_chord_fm, mapping = cm_chord_aes_fm, colour = "#D55E00"
  ) +
  ggplot2::geom_point(data = cm_mid_fm, colour = "#D55E00", size = 3) +
  ggplot2::facet_wrap(~panel, scales = "free_y") +
  ggplot2::labs(x = "x", y = NULL)
Show code
import matplotlib.pyplot as plt
import numpy as np

cm_x_fm = np.linspace(-1, 3, 201)
fig, axes = plt.subplots(1, 2, figsize=(7, 3.5), layout="constrained")
axes[0].plot(cm_x_fm, cm_x_fm, color="grey", linewidth=0.8)
axes[0].plot(cm_x_fm, cm_x_fm**2, color="grey", linewidth=0.8)
axes[0].plot(cm_x_fm, np.maximum(cm_x_fm, cm_x_fm**2), color="#0072B2")
axes[0].set_title("max{x, x^2}")
axes[1].plot(cm_x_fm, np.minimum(cm_x_fm**2, (cm_x_fm - 2)**2), color="#0072B2")
axes[1].plot([0, 2], [0, 0], "o-", color="#D55E00", markersize=6)
axes[1].plot(1, 1, "o", color="#D55E00", markersize=8)
axes[1].set_title("min{x^2, (x - 2)^2}")
for ax in axes:
    ax.set_xlabel("x")
plt.show()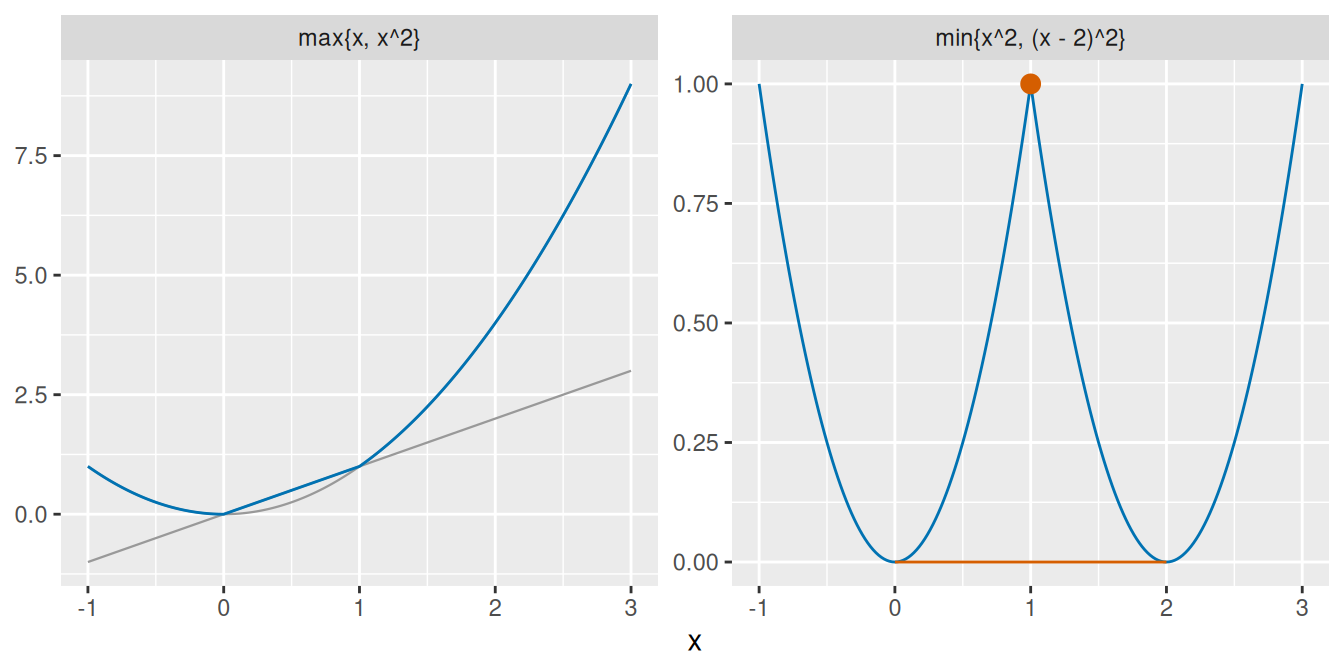
DefDefinition 6 (Epigraph)
Definition 6 (Epigraph) The epigraph [3] of \(f : \mathbb{R}^p \to \mathbb{R}\) is the set of points on or over its graph,
\[ \operatorname{epi} f \stackrel{\text{def}}{=}\mathopen{}\left\{(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}, s) : \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}\in \mathbb{R}^p,\ s \in \mathbb{R},\ f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}) \le s\right\}\mathclose{}. \]
A pair \((\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}, s)\) is treated as the \((p + 1)\)-vector with entries \(x_1, \ldots, x_p, s\), so \(\operatorname{epi} f \subseteq \mathbb{R}^{p+1}\), and sums and multiples of pairs are taken entry by entry.
Example 7 (The epigraph of \(x^2\)) For \(f(x) = x^2\), \(\operatorname{epi} f = \mathopen{}\left\{(x, s) : x^2 \le s\right\}\mathclose{}\), the points \((x, s)\) on the parabola \(s = x^2\) or on the side of it where \(s\) is larger. \((1, 2)\) is in it, since \(1^2 \le 2\); \((2, 1)\) is not, since \(2^2 > 1\).
Show code
ep_x_fe <- seq(-2, 2, length.out = 201)
ep_curve_fe <- tibble::tibble(x = ep_x_fe, s = ep_x_fe^2, top = 5)
ep_marks_x_fe <- c(1, 2)
ep_marks_s_fe <- c(2, 1)
ep_marks_kind_fe <- c("in the epigraph", "not in the epigraph")
ep_marks_fe <- tibble::tibble(
  x = ep_marks_x_fe, s = ep_marks_s_fe, kind = ep_marks_kind_fe
)
ep_aes_fe <- ggplot2::aes(x, s)
ep_ribbon_aes_fe <- ggplot2::aes(ymin = s, ymax = top)
ep_marks_aes_fe <- ggplot2::aes(shape = kind)
ep_shapes_fe <- c("in the epigraph" = 16, "not in the epigraph" = 4)
ggplot2::ggplot(ep_curve_fe, ep_aes_fe) +
  ggplot2::geom_ribbon(
    mapping = ep_ribbon_aes_fe, fill = "#0072B2", alpha = 0.15
  ) +
  ggplot2::geom_line(colour = "#0072B2") +
  ggplot2::geom_point(
    data = ep_marks_fe, mapping = ep_marks_aes_fe,
    colour = "#D55E00", size = 3
  ) +
  ggplot2::scale_shape_manual(values = ep_shapes_fe) +
  ggplot2::labs(x = "x", y = "s", shape = NULL)
Show code
import matplotlib.pyplot as plt
import numpy as np

ep_x_fe = np.linspace(-2, 2, 201)
fig, ax = plt.subplots(figsize=(5, 4), layout="constrained")
ax.fill_between(ep_x_fe, ep_x_fe**2, 5, color="#0072B2", alpha=0.15)
ax.plot(ep_x_fe, ep_x_fe**2, color="#0072B2")
ax.plot(1, 2, "o", color="#D55E00", markersize=8, label="in the epigraph")
ax.plot(2, 1, "x", color="#D55E00", markersize=8, label="not in the epigraph")
ax.set_ylim(0, 5)
#> (0.0, 5.0)
ax.set_xlabel("x")
ax.set_ylabel("s")
ax.legend(loc="upper center")
plt.show()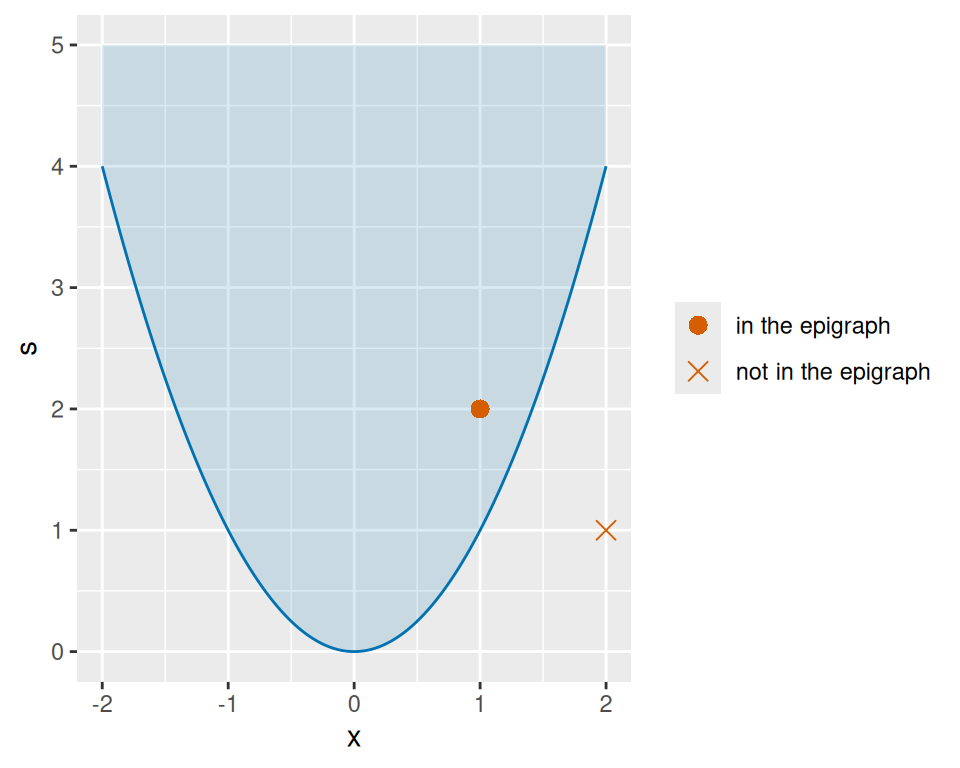
LemTheorem 3 (Convexity through the epigraph)
Theorem 3 (Convexity through the epigraph) \(f : \mathbb{R}^p \to \mathbb{R}\) is convex if and only if its epigraph (Definition 6) is convex (Definition 1).
ProofProof
Proof. If. Let \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}, \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}\in \mathbb{R}^p\) and \(t \in [0, 1]\). The points \((\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}, f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}))\) and \((\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}, f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}))\) are in \(\operatorname{epi} f\), since \(f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}) \le f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}})\) and \(f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}) \le f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}})\). Since \(\operatorname{epi} f\) is convex, it contains
\[ t\,(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}, f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}})) + (1 - t)\,(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}, f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}})) = \mathopen{}\left(t \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}+ (1 - t) \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}},\ t f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}) + (1 - t) f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}})\right)\mathclose{}, \]
and by Definition 6 that membership means \(f(t \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}+ (1 - t) \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}) \le t f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}) + (1 - t) f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}})\).
Only if. Let \((\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}, s)\) and \((\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}, u)\) be in \(\operatorname{epi} f\), so \(f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}) \le s\) and \(f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}) \le u\), and let \(t \in [0, 1]\). Then
\[ \begin{aligned} f(t \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}+ (1 - t) \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}) &\le t f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}) + (1 - t) f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}) && \text{(} f \text{ is convex)} \\ &\le t s + (1 - t) u, && \text{(} f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}) \le s \text{, } f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}) \le u \text{, and } t, 1 - t \ge 0 \text{)} \end{aligned} \]
so \(t\,(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}, s) + (1 - t)\,(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}, u) = (t \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}+ (1 - t) \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}},\ t s + (1 - t) u)\) is in \(\operatorname{epi} f\).
ExmExample 8 (Two epigraphs)
Example 8 (Two epigraphs)
- The epigraph of \(f(x) = \mathopen{}\left|x\right|\mathclose{}\) is \(\mathopen{}\left\{(x, s) : \mathopen{}\left|x\right|\mathclose{} \le s\right\}\mathclose{}\), a wedge. It is the intersection of the half-planes \(\mathopen{}\left\{(x, s) : s - x \ge 0\right\}\mathclose{}\) and \(\mathopen{}\left\{(x, s) : s + x \ge 0\right\}\mathclose{}\). Each half-plane is convex: if \(s_1 - x_1 \ge 0\) and \(s_2 - x_2 \ge 0\), then \((t s_1 + (1 - t) s_2) - (t x_1 + (1 - t) x_2) = t (s_1 - x_1) + (1 - t)(s_2 - x_2) \ge 0\), and the same with \(+\) for the other. So the wedge is convex (Theorem 1), and \(\mathopen{}\left|x\right|\mathclose{}\) is convex by Theorem 3.
- The epigraph of \(g(x) = -x^2\) is not convex: \((-1, -1)\) and \((1, -1)\) are in it, since \(g(\pm 1) = -1\), but their midpoint \((0, -1)\) is not, since \(g(0) = 0 > -1\). So \(-x^2\) is not convex.
DefDefinition 7 (Tangent plane)
Definition 7 (Tangent plane) Let \(f : \mathbb{R}^p \to \mathbb{R}\) have a gradient at \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}\) (gradient). The tangent plane [4] to the graph of \(f\) at \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}\) is the graph of the function
\[ \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}\mapsto f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}) + {\mathopen{}\left(\frac{\partial}{\partial \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}} f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}})\right)\mathclose{}}^{\top} (\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}- \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}), \]
which takes the value \(f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}})\) at \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}= \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}\) and has the same gradient as \(f\) there.
ExmExample 9 (A tangent line and a tangent plane)
Example 9 (A tangent line and a tangent plane)
-
For \(f(x) = x^2\) at \(y = 1\), \(f(1) = 1\) and \(f'(1) = 2\), so the tangent line is
\[ \begin{aligned} s &= 1 + 2\,(x - 1) && \text{(substitute } f(1) \text{ and } f'(1) \text{)} \\ &= 1 + 2x - 2 && \text{(distribute)} \\ &= 2x - 1. && \text{(} 1 - 2 = -1 \text{)} \end{aligned} \]
-
For \(f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}) = x_1^2 + x_2^2\) at \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}= {(1, 1)}^{\top}\), \(f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}) = 2\) and the gradient is \({(2 y_1,\ 2 y_2)}^{\top} = {(2, 2)}^{\top}\), so the tangent plane is
\[ \begin{aligned} s &= 2 + 2\,(x_1 - 1) + 2\,(x_2 - 1) && \text{(substitute } f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}) \text{ and the gradient)} \\ &= 2 + 2 x_1 - 2 + 2 x_2 - 2 && \text{(distribute)} \\ &= 2 x_1 + 2 x_2 - 2. && \text{(} 2 - 2 - 2 = -2 \text{)} \end{aligned} \]
RemarkRemark 1 (The tangent plane in one variable)
Remark 1 (The tangent plane in one variable). For \(p = 1\) the tangent plane is the tangent line \(s = f(y) + f'(y)\,(x - y)\), the line through \((y, f(y))\) with slope \(f'(y)\).
LemTheorem 4 (First-order characterization of convexity)
Theorem 4 (First-order characterization of convexity) Let \(f : \mathbb{R}^p \to \mathbb{R}\) have first partial derivatives that are continuous on \(\mathbb{R}^p\) (continuity). Then \(f\) is convex if and only if
\[ f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}) \ge f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}) + {\mathopen{}\left(\frac{\partial}{\partial \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}} f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}})\right)\mathclose{}}^{\top} (\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}- \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}) \qquad \text{for all } \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}, \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}\in \mathbb{R}^p: \tag{1}\]
every tangent plane (Definition 7) lies on or under the graph. If the inequality is strict whenever \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}\ne \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}\), then \(f\) is strictly convex (Definition 3).
ProofProof
Proof. Only if. Let \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}, \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}\in \mathbb{R}^p\), let \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{d}}\vphantom{d}} \stackrel{\text{def}}{=}\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}- \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}\), and let \(g(t) \stackrel{\text{def}}{=}f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}+ t \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{d}}\vphantom{d}})\). The inner function \(t \mapsto \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}+ t \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{d}}\vphantom{d}}\) has derivative \({\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{d}}\vphantom{d}}}^{\top}\) (vector-valued derivative), so the vector chain rule (vector chain rule) gives
\[ \begin{aligned} g'(0) &= {\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{d}}\vphantom{d}}}^{\top}\,\frac{\partial}{\partial \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}} f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}) && \text{(vector chain rule)} \\ &= {\mathopen{}\left(\frac{\partial}{\partial \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}} f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}})\right)\mathclose{}}^{\top} \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{d}}\vphantom{d}}. && \text{(a } 1 \times 1 \text{ matrix equals its transpose)} \end{aligned} \]
For \(t \in (0, 1]\), \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}+ t \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{d}}\vphantom{d}} = t \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}+ (1 - t) \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}\), so
\[ \begin{aligned} g(t) - g(0) &= f(t \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}+ (1 - t) \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}) - f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}) && \text{(definition of } g \text{)} \\ &\le t f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}) + (1 - t) f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}) - f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}) && \text{(} f \text{ is convex)} \\ &= t\,(f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}) - f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}})), && \text{(collect terms)} \end{aligned} \]
and dividing by \(t > 0\), \(\dfrac{g(t) - g(0)}{t} \le f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}) - f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}})\). As \(t \to 0\) from the right, the left side tends to \(g'(0)\) (\(g\) is differentiable at \(0\), so the one-sided limit equals the two-sided derivative), and a limit of numbers that are all at most \(f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}) - f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}})\) is at most \(f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}) - f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}})\). So \({\mathopen{}\left(\frac{\partial}{\partial \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}} f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}})\right)\mathclose{}}^{\top} (\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}- \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}) \le f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}) - f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}})\), which rearranges to Equation 1.
If. Let \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}, \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}\in \mathbb{R}^p\), \(t \in [0, 1]\), \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{z}}\vphantom{z}} \stackrel{\text{def}}{=}t \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}+ (1 - t) \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}\), and \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{g}}\vphantom{g}} \stackrel{\text{def}}{=}\frac{\partial}{\partial \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}} f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{z}}\vphantom{z}})\). Applying Equation 1 at the point \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{z}}\vphantom{z}}\), once toward \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}\) and once toward \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}\),
\[ f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}) \ge f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{z}}\vphantom{z}}) + {\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{g}}\vphantom{g}}}^{\top} (\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}- \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{z}}\vphantom{z}}), \qquad f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}) \ge f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{z}}\vphantom{z}}) + {\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{g}}\vphantom{g}}}^{\top} (\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}- \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{z}}\vphantom{z}}). \]
Multiplying the first by \(t \ge 0\) and the second by \(1 - t \ge 0\) and adding,
\[ \begin{aligned} t f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}) + (1 - t) f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}) &\ge t \mathopen{}\left(f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{z}}\vphantom{z}}) + {\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{g}}\vphantom{g}}}^{\top} (\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}- \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{z}}\vphantom{z}})\right)\mathclose{} + (1 - t) \mathopen{}\left(f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{z}}\vphantom{z}}) + {\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{g}}\vphantom{g}}}^{\top} (\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}- \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{z}}\vphantom{z}})\right)\mathclose{} && \text{(multiply by } t, 1 - t \ge 0 \text{ and add)} \\ &= (t + (1 - t))\,f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{z}}\vphantom{z}}) + t\,{\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{g}}\vphantom{g}}}^{\top} (\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}- \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{z}}\vphantom{z}}) + (1 - t)\,{\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{g}}\vphantom{g}}}^{\top} (\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}- \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{z}}\vphantom{z}}) && \text{(distribute } t \text{ and } 1 - t \text{)} \\ &= f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{z}}\vphantom{z}}) + t\,{\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{g}}\vphantom{g}}}^{\top} (\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}- \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{z}}\vphantom{z}}) + (1 - t)\,{\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{g}}\vphantom{g}}}^{\top} (\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}- \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{z}}\vphantom{z}}) && \text{(} t + (1 - t) = 1 \text{)} \\ &= f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{z}}\vphantom{z}}) + {\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{g}}\vphantom{g}}}^{\top} \mathopen{}\left(t (\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}- \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{z}}\vphantom{z}}) + (1 - t) (\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}- \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{z}}\vphantom{z}})\right)\mathclose{} && \text{(factor out } {\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{g}}\vphantom{g}}}^{\top} \text{; matrix products distribute)} \\ &= f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{z}}\vphantom{z}}) + {\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{g}}\vphantom{g}}}^{\top} \mathopen{}\left(t \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}+ (1 - t) \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}- \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{z}}\vphantom{z}}\right)\mathclose{} && \text{(collect terms)} \\ &= f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{z}}\vphantom{z}}). && \text{(definition of } \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{z}}\vphantom{z}} \text{)} \end{aligned} \]
That inequality is the defining inequality of a convex function. If Equation 1 is strict for distinct points, and \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}\ne \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}\) and \(t \in (0, 1)\), then:
- \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{z}}\vphantom{z}}\) differs from both \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}\) and \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}\), since \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}- \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{z}}\vphantom{z}} = (1 - t)(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}- \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}) \ne \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{0}}\vphantom{0}}\) and \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}- \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{z}}\vphantom{z}} = t (\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}- \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}) \ne \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{0}}\vphantom{0}}\);
- so both inequalities at \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{z}}\vphantom{z}}\) are strict;
- both multipliers \(t\) and \(1 - t\) are positive, so the first step of the display is strict, and \(f\) is strictly convex.
ExmExample 10 (Tangent lines under a parabola)
Example 10 (Tangent lines under a parabola) For \(f(x) = x^2\), the right side of Equation 1 is \(y^2 + 2y (x - y) = 2xy - y^2\), and
\[ \begin{aligned} f(x) - (2xy - y^2) &= x^2 - 2xy + y^2 \\ &= (x - y)^2 \\ &\ge 0, \end{aligned} \]
with equality only at \(x = y\), confirming that \(x^2\) is strictly convex. For \(g(x) = -x^2\) the inequality fails: at \(y = 0\) the tangent line is \(s = 0\), and \(g(1) = -1 < 0\).
Show code
tl_x_ft <- seq(-1, 3, length.out = 201)
tl_curve_ft <- tibble::tibble(x = tl_x_ft, s = tl_x_ft^2)
tl_line_ft <- tibble::tibble(x = tl_x_ft, s = 2 * tl_x_ft - 1)
tl_point_ft <- tibble::tibble(x = 1, s = 1)
tl_aes_ft <- ggplot2::aes(x, s)
ggplot2::ggplot(tl_curve_ft, tl_aes_ft) +
  ggplot2::geom_line(colour = "#0072B2") +
  ggplot2::geom_line(
    data = tl_line_ft, colour = "#D55E00", linetype = "dashed"
  ) +
  ggplot2::geom_point(data = tl_point_ft, colour = "#D55E00", size = 3) +
  ggplot2::labs(x = "x", y = "s")
Show code
import matplotlib.pyplot as plt
import numpy as np

tl_x_ft = np.linspace(-1, 3, 201)
fig, ax = plt.subplots(figsize=(5, 4), layout="constrained")
ax.plot(tl_x_ft, tl_x_ft**2, color="#0072B2", label="f(x) = x^2")
ax.plot(tl_x_ft, 2 * tl_x_ft - 1, "--", color="#D55E00",
        label="tangent line at 1")
ax.plot(1, 1, "o", color="#D55E00", markersize=8)
ax.set_xlabel("x")
ax.set_ylabel("s")
ax.legend(loc="upper center")
plt.show()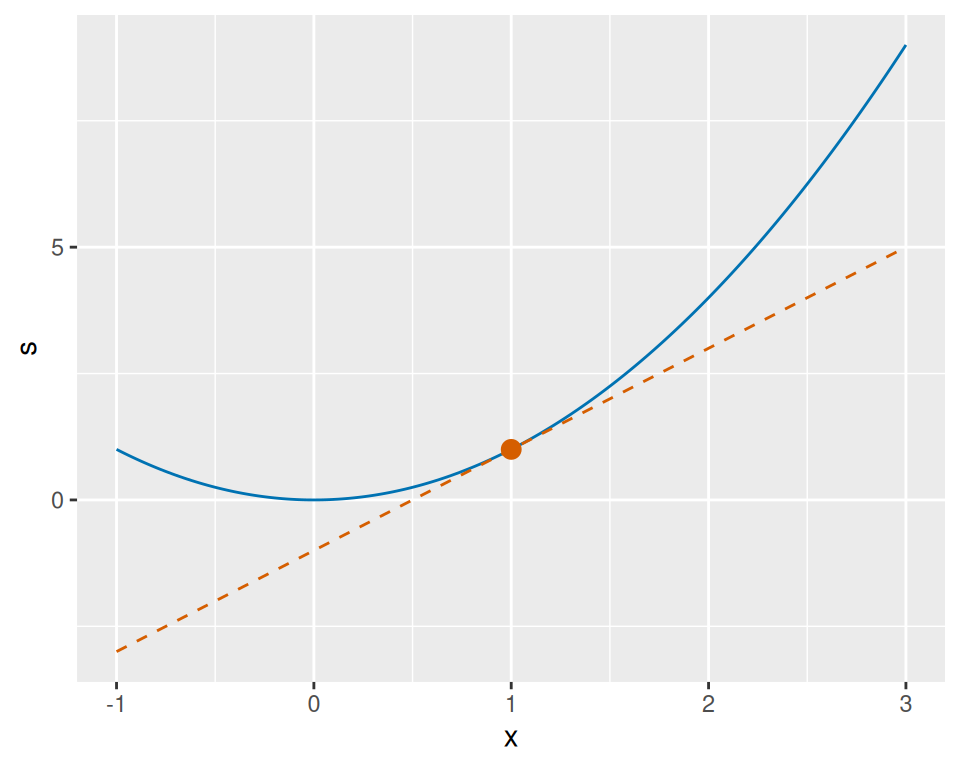
LemTheorem 5 (Second-derivative test for convexity)
Theorem 5 (Second-derivative test for convexity) Let \(f : \mathbb{R}^p \to \mathbb{R}\) have first and second partial derivatives that are continuous on \(\mathbb{R}^p\) (continuity).
- If \(\mathbf{H}_f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}})\) is positive semidefinite for every \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}\), then \(f\) is convex.
- If \(\mathbf{H}_f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}})\) is positive definite for every \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}\), then \(f\) is strictly convex (Definition 3).
ProofProof
Proof. Let \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}, \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}\in \mathbb{R}^p\). By Theorem 6 in Critical Points and Optimality Conditions with \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{z}}\vphantom{z}} = \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}\) and \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{h}}\vphantom{h}} = \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}- \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}\), there is a \(\tau\in (0, 1)\) such that, with \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{w}}\vphantom{w}} \stackrel{\text{def}}{=}\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}+ \tau(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}- \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}})\),
\[ \begin{aligned} f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}) &= f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}) + {\mathopen{}\left(\frac{\partial}{\partial \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}} f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}})\right)\mathclose{}}^{\top} (\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}- \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}) + \frac{1}{2}\,{(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}- \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}})}^{\top}\,\mathbf{H}_f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{w}}\vphantom{w}})\,(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}- \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}) && \text{(}\href{optimization-critical-points.qmd#thm-taylor-mv}{\text{Theorem~6 in Critical Points and Optimality Conditions}}\text{)} \\ &\ge f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}) + {\mathopen{}\left(\frac{\partial}{\partial \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}} f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}})\right)\mathclose{}}^{\top} (\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}- \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}). && \text{(} \mathbf{H}_f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{w}}\vphantom{w}}) \text{ is positive semidefinite)} \end{aligned} \]
This inequality is Equation 1, so \(f\) is convex by Theorem 4. Under the hypothesis of part 2 and with \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}\ne \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}\), the quadratic-form term is positive, so the inequality is strict, and \(f\) is strictly convex by the last sentence of Theorem 4.
ExmExample 11 (Using the Hessian to show convexity)
Example 11 (Using the Hessian to show convexity)
For a symmetric positive semidefinite \(\mathbf{A}\), \(f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}) = {\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}}^{\top} \mathbf{A} \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}\) has Hessian \(2 \mathbf{A}\) (Hessian of a quadratic form), which is positive semidefinite because \({\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{h}}\vphantom{h}}}^{\top} (2 \mathbf{A}) \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{h}}\vphantom{h}} = 2\,{\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{h}}\vphantom{h}}}^{\top} \mathbf{A} \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{h}}\vphantom{h}} \ge 0\); so \(f\) is convex.
\(f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}) = x_1^2 + x_2^2 - 2 x_1\) has Hessian \(2 \mathbf{I}_2\) (Example 15 in Critical Points and Optimality Conditions), which is positive definite, so \(f\) is strictly convex.
-
\(f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}) = e^{2x_1 + x_2} - x_1\) has Hessian \(e^{u} \begin{bmatrix} 4 & 2 \\ 2 & 1 \end{bmatrix}\) with \(u = 2x_1 + x_2\) (Example), and
\[ \begin{aligned} {\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{h}}\vphantom{h}}}^{\top}\,\mathbf{H}_f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}})\,\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{h}}\vphantom{h}} &= e^{u} (4 h_1^2 + 4 h_1 h_2 + h_2^2) \\ &= e^{u} (2 h_1 + h_2)^2 \\ &\ge 0, \end{aligned} \]
so \(f\) is convex. The Hessian is not positive definite (\(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{h}}\vphantom{h}} = {(1, -2)}^{\top}\) gives \(0\)), so part 2 does not apply, and in fact \(f\) is not strictly convex: along \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}= t\,{(1, -2)}^{\top}\),
\[ \begin{aligned} u &= 2t - 2t \\ &= 0 \end{aligned} \]
and \(f = 1 - t\) is linear in \(t\), so the convexity inequality holds with equality there.
ExmExample 12 (Strictly convex with a singular Hessian)
Example 12 (Strictly convex with a singular Hessian) Part 2 is sufficient but not necessary. \(f(x) = x^4\) has
\[ \begin{aligned} f''(0) &= 12 \cdot 0^2 \\ &= 0, \end{aligned} \]
so \(\mathbf{H}_f(0) = [0]\) is singular and not positive definite. Yet \(f\) is strictly convex, by the strict form of Equation 1: for \(x \ne y\),
\[ \begin{aligned} x^4 - y^4 - 4 y^3 (x - y) &= (x - y)(x^3 + x^2 y + x y^2 + y^3) - 4 y^3 (x - y) && \text{(factor } x^4 - y^4 \text{)} \\ &= (x - y)(x^3 + x^2 y + x y^2 - 3 y^3) && \text{(collect the } y^3 \text{ terms)} \\ &= (x - y)^2 (x^2 + 2 x y + 3 y^2) && \text{(} (x - y)(x^2 + 2 x y + 3 y^2) = x^3 + x^2 y + x y^2 - 3 y^3 \text{)} \\ &= (x - y)^2 \mathopen{}\left((x + y)^2 + 2 y^2\right)\mathclose{}, && \text{(complete the square)} \end{aligned} \]
which is positive: \((x - y)^2 > 0\), and \((x + y)^2 + 2 y^2 = 0\) would need \(y = 0\) and then
\[ \begin{aligned} x &= 0 \\ &= y. \end{aligned} \]
LemTheorem 6 (A convex function has a positive semidefinite Hessian)
Theorem 6 (A convex function has a positive semidefinite Hessian) Let \(f : \mathbb{R}^p \to \mathbb{R}\) have first and second partial derivatives that are continuous on \(\mathbb{R}^p\). If \(f\) is convex, then the Hessian \(\mathbf{H}_f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}})\) is positive semidefinite for every \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}\in \mathbb{R}^p\).
ProofProof
Proof. Fix \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}, \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{v}}\vphantom{v}} \in \mathbb{R}^p\). Let \(h > 0\). By Theorem 6 in Critical Points and Optimality Conditions applied with \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{z}}\vphantom{z}} = \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}\) and \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{h}}\vphantom{h}} = h\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{v}}\vphantom{v}}\), and again with \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{h}}\vphantom{h}} = -h\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{v}}\vphantom{v}}\), there are \(\tau_+, \tau_- \in (0, 1)\) with
\[ \begin{aligned} f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}+ h\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{v}}\vphantom{v}}) &= f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}) + h\,{\mathopen{}\left(\frac{\partial}{\partial \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}} f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}})\right)\mathclose{}}^{\top} \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{v}}\vphantom{v}} + \frac{h^2}{2}\,{\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{v}}\vphantom{v}}}^{\top}\,\mathbf{H}_f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{w}}\vphantom{w}}_+)\,\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{v}}\vphantom{v}} && \text{(}\href{optimization-critical-points.qmd#thm-taylor-mv}{\text{Theorem~6 in Critical Points and Optimality Conditions}}\text{)} \\ f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}- h\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{v}}\vphantom{v}}) &= f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}) - h\,{\mathopen{}\left(\frac{\partial}{\partial \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}} f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}})\right)\mathclose{}}^{\top} \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{v}}\vphantom{v}} + \frac{h^2}{2}\,{\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{v}}\vphantom{v}}}^{\top}\,\mathbf{H}_f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{w}}\vphantom{w}}_-)\,\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{v}}\vphantom{v}}, && \text{(}\href{optimization-critical-points.qmd#thm-taylor-mv}{\text{Theorem~6 in Critical Points and Optimality Conditions}}\text{)} \end{aligned} \]
where \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{w}}\vphantom{w}}_\pm = \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}\pm \tau_\pm h\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{v}}\vphantom{v}}\). Adding the two equations cancels the first-order summands:
\[ f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}+ h\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{v}}\vphantom{v}}) + f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}- h\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{v}}\vphantom{v}}) - 2 f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}) = \frac{h^2}{2}\,{\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{v}}\vphantom{v}}}^{\top}\mathopen{}\left(\mathbf{H}_f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{w}}\vphantom{w}}_+) + \mathbf{H}_f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{w}}\vphantom{w}}_-)\right)\mathclose{}\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{v}}\vphantom{v}}. \]
Since \(f\) is convex and \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}= \frac{1}{2}(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}+ h\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{v}}\vphantom{v}}) + \frac{1}{2}(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}- h\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{v}}\vphantom{v}})\),
\[ f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}) \le \frac{1}{2} f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}+ h\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{v}}\vphantom{v}}) + \frac{1}{2} f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}- h\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{v}}\vphantom{v}}), \]
so the left side of the previous display is nonnegative. Dividing by \(h^2 / 2\) gives
\[ {\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{v}}\vphantom{v}}}^{\top}\mathopen{}\left(\mathbf{H}_f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{w}}\vphantom{w}}_+) + \mathbf{H}_f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{w}}\vphantom{w}}_-)\right)\mathclose{}\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{v}}\vphantom{v}} \ge 0 \qquad \text{for every } h > 0. \]
As \(h \to 0\), both \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{w}}\vphantom{w}}_+\) and \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{w}}\vphantom{w}}_-\) approach \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}\), and the entries of \(\mathbf{H}_f\) are continuous, so the left side approaches \(2\,{\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{v}}\vphantom{v}}}^{\top}\,\mathbf{H}_f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}})\,\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{v}}\vphantom{v}}\). Therefore \({\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{v}}\vphantom{v}}}^{\top}\,\mathbf{H}_f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}})\,\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{v}}\vphantom{v}} \ge 0\) for every \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{v}}\vphantom{v}}\).
CorCorollary 1 (Stationary points of a convex function are global minimizers)
Corollary 1 (Stationary points of a convex function are global minimizers) If \(f\) is as in Theorem 4 and convex, then every stationary point \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}^*\) of \(f\) (Definition 4 in Critical Points and Optimality Conditions) is a global minimizer.
ProofProof
Proof. For every \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}\),
\[ \begin{aligned} f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}) &\ge f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}^*) + {\mathopen{}\left(\frac{\partial}{\partial \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}} f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}^*)\right)\mathclose{}}^{\top} (\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}- \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}^*) && \text{(}\href{#eq-supporting-hyperplane}{\text{Equation~1}}\text{ with } \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}= \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}^* \text{)} \\ &= f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}^*) + {\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{0}}\vphantom{0}}}^{\top} (\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}- \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}^*) && \text{(} \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}^* \text{ is stationary)} \\ &= f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}^*). && \text{(} \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{0}}\vphantom{0}} \cdot \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{v}}\vphantom{v}} = 0 \text{)} \end{aligned} \]
ExmExample 13 (A convex function, and a non-convex one)
Example 13 (A convex function, and a non-convex one)
- \(f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}) = x_1^2 + x_2^2 - 2 x_1\) is convex by Theorem 5, since its Hessian is \(2 \mathbf{I}_2\) (Example 15 in Critical Points and Optimality Conditions), so its stationary point \({(1, 0)}^{\top}\) (Example 7 in Critical Points and Optimality Conditions) is a global minimizer, as completing the square showed in Example 8 in Critical Points and Optimality Conditions.
- Without convexity, a stationary point need not be a minimizer at all: \(x_1^2 - x_2^2\) has the stationary point \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{0}}\vphantom{0}}\), which is not a minimizer (Example 8 in Critical Points and Optimality Conditions).
- The corollary says nothing about whether a minimizer exists: \(e^{2x_1 + x_2} - x_1\) is convex (Example 11) but has no stationary point, and so no local minimizer (Example 8 in Critical Points and Optimality Conditions).
Definitions on this page
References
[1]
H. Zhou, “Optimization and multivariate calculus.” Lecture notes for Biostat 216, Mathematical Methods for Biostatistics, University of California, Los Angeles, 2024. Accessed: Oct. 05, 2026. [Online]. Available: https://ucla-biostat-216.github.io/2024fall/slides/13-optim/13-optim.html
[2]
Wikipedia contributors, “Convex set — Wikipedia, the free encyclopedia.” 2026. Available: https://en.wikipedia.org/wiki/Convex_set
[3]
Wikipedia contributors, “Epigraph (mathematics) — Wikipedia, the free encyclopedia.” 2026. Available: https://en.wikipedia.org/wiki/Epigraph_(mathematics)
[4]
Wikipedia contributors, “Tangent space — Wikipedia, the free encyclopedia.” 2026. Available: https://en.wikipedia.org/wiki/Tangent_space