Convexity in Several Variables
Last modified: 2026-10-31 15:22:31 (PDT)
1 Convexity in several variables
Source
This section is adapted from the convexity part of Zhou [1], used under the MIT License (see the license text in Linear Algebra). The source states the first-order test (in one direction) and the second-derivative test for convexity without proof; here both directions of the first-order test are proved, and the second-derivative test is proved from the Taylor theorem of Section 2 in Critical Points and Optimality Conditions. The source defines both concave and strictly concave as “\(-f\) is strictly convex”; here \(f\) is concave when \(-f\) is convex. The source states that an intersection of convex sets is convex and that a maximum of convex functions is convex for any finite number of them; here each is stated for two and the general case follows by induction. These parts of the source are not part of this section:
- its catalogs of convex sets and convex functions, including the positive semidefinite matrices and \(-\log \det\)
- intersections of infinitely many convex sets, and suprema of infinitely many convex functions
- its examples, exercises and figures, including the multivariate normal maximum likelihood example
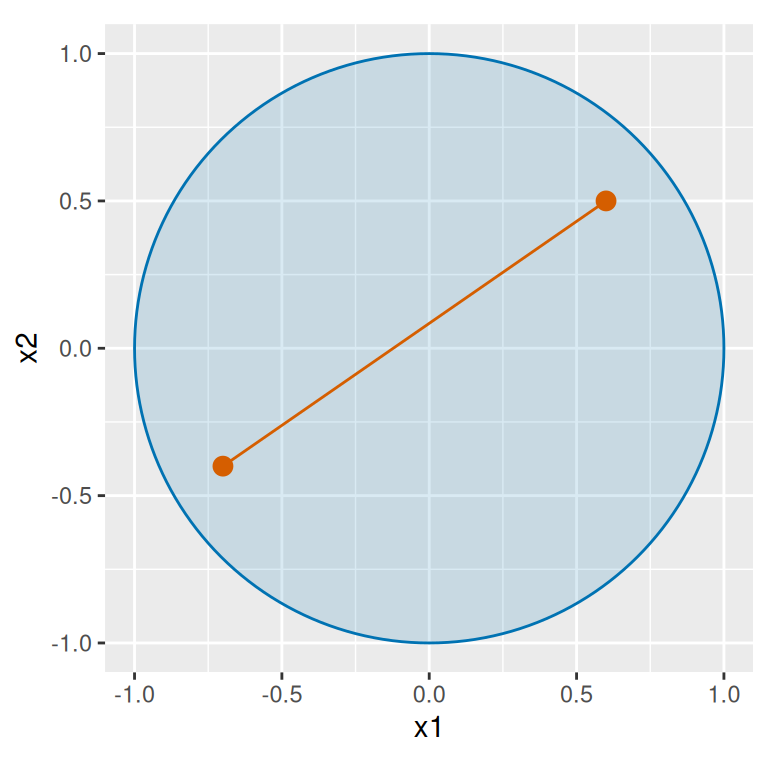
Definition 1 (Convex set) A set \(K \subseteq \mathbb{R}^p\) is convex if [2] for all \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}, \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}\in K\) and all \(t \in [0, 1]\), the point \(t \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}+ (1 - t) \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}\) is in \(K\): \(K\) contains the whole line segment between any two of its points.
Example 1 (Convex sets)
\(\mathbb{R}^p\) is convex, and so is any set with at most one point.
-
The closed ball (closed ball) \(B = \mathopen{}\left\{\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}: \mathopen{}\left\lVert\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}\right\rVert\mathclose{} \le r\right\}\mathclose{}\) is convex: for \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}, \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}\in B\) and \(t \in [0, 1]\),
\[ \begin{aligned} \mathopen{}\left\lVert t \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}+ (1 - t) \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}\right\rVert\mathclose{} &\le \mathopen{}\left\lVert t \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}\right\rVert\mathclose{} + \mathopen{}\left\lVert(1 - t) \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}\right\rVert\mathclose{} && \text{(triangle inequality)} \\ &= t\,\mathopen{}\left\lVert\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}\right\rVert\mathclose{} + (1 - t)\,\mathopen{}\left\lVert\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}\right\rVert\mathclose{} && \text{(norm of a multiple; } t, 1 - t \ge 0 \text{)} \\ &\le t\,r + (1 - t)\,r && \text{(} \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}, \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}\in B \text{)} \\ &= r. && \text{(arithmetic)} \end{aligned} \]
The first step is the triangle inequality, and the second uses the norm of a multiple.
Example 2 (A set that is not convex) \(K = \mathopen{}\left\{x \in \mathbb{R}: \mathopen{}\left|x\right|\mathclose{} \ge 1\right\}\mathclose{}\) is not convex: \(-1\) and \(1\) are in \(K\), but with \(t = \tfrac{1}{2}\) the point \(\tfrac{1}{2}(-1) + \tfrac{1}{2}(1) = 0\) is not.
[Code]
cs_angle_fc <- seq(0, 2 * pi, length.out = 201)
cs_cos_fc <- cos(cs_angle_fc)
cs_sin_fc <- sin(cs_angle_fc)
cs_disk_fc <- tibble::tibble(x1 = cs_cos_fc, x2 = cs_sin_fc)
cs_points_x1_fc <- c(-0.7, 0.6)
cs_points_x2_fc <- c(-0.4, 0.5)
cs_points_fc <- tibble::tibble(x1 = cs_points_x1_fc, x2 = cs_points_x2_fc)
cs_segment_fc <- tibble::tibble(
  x1 = -0.7, x2 = -0.4, x1_end = 0.6, x2_end = 0.5
)
cs_aes_fc <- ggplot2::aes(x1, x2)
cs_seg_aes_fc <- ggplot2::aes(xend = x1_end, yend = x2_end)
ggplot2::ggplot(cs_disk_fc, cs_aes_fc) +
  ggplot2::geom_polygon(fill = "#0072B2", alpha = 0.15, colour = "#0072B2") +
  ggplot2::geom_segment(
    data = cs_segment_fc, mapping = cs_seg_aes_fc, colour = "#D55E00"
  ) +
  ggplot2::geom_point(data = cs_points_fc, colour = "#D55E00", size = 3) +
  ggplot2::coord_fixed() +
  ggplot2::labs(x = "x1", y = "x2")
[Code]
import matplotlib.pyplot as plt
import numpy as np

cs_angle_fc = np.linspace(0, 2 * np.pi, 201)
cs_x1_fc = np.array([-0.7, 0.6])
cs_x2_fc = np.array([-0.4, 0.5])
fig, ax = plt.subplots(figsize=(4, 4), layout="constrained")
ax.fill(np.cos(cs_angle_fc), np.sin(cs_angle_fc), color="#0072B2", alpha=0.15)
ax.plot(np.cos(cs_angle_fc), np.sin(cs_angle_fc), color="#0072B2")
ax.plot(cs_x1_fc, cs_x2_fc, "o-", color="#D55E00", markersize=8)
ax.set_aspect("equal")
ax.set_xlabel("x1")
ax.set_ylabel("x2")
plt.show()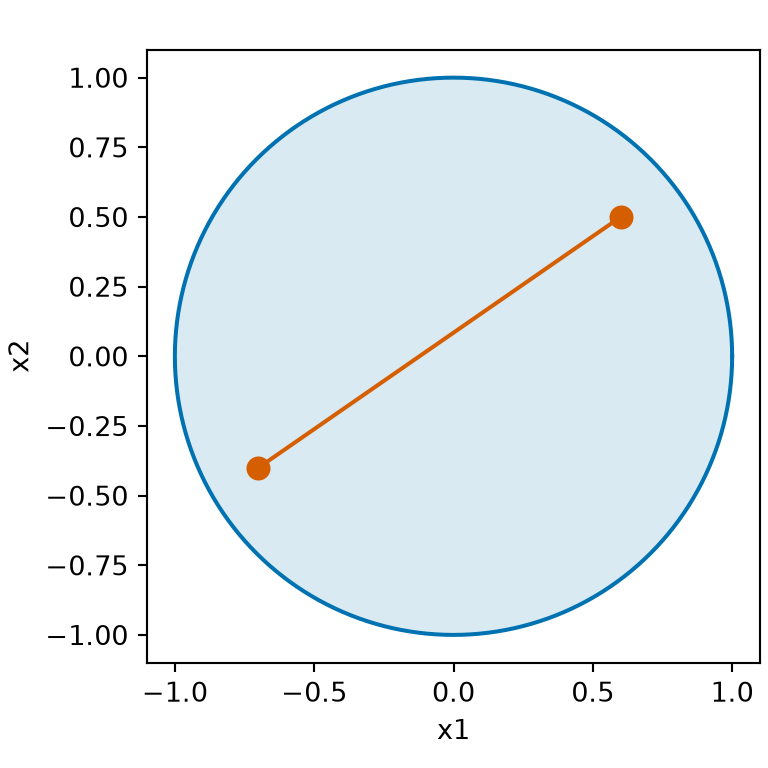
Definition 2 (Half-space) Let \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{a}}\vphantom{a}} \in \mathbb{R}^p\) be a nonzero vector and \(c\) a real number. The set \(\mathopen{}\left\{\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}\in \mathbb{R}^p : \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{a}}\vphantom{a}} \cdot \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}} \ge c\right\}\mathclose{}\) is a (closed) half-space: the points on one side of the boundary \(\mathopen{}\left\{\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}: \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{a}}\vphantom{a}} \cdot \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}} = c\right\}\mathclose{}\), together with the boundary. In \(\mathbb{R}^2\), a half-space is called a half-plane.
Example 3 (The right half-plane) With \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{a}}\vphantom{a}} = {(1, 0)}^{\top}\) and \(c = 0\), the half-plane \(\mathopen{}\left\{\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}\in \mathbb{R}^2 : x_1 \ge 0\right\}\mathclose{}\) is the set of points on or to the right of the \(x_2\)-axis. \({(1, 5)}^{\top}\) is in it, since \(1 \ge 0\); \({(0, -3)}^{\top}\) is in it, on the boundary; and \({(-1, 0)}^{\top}\) is not, since \(-1 < 0\).
Theorem 1 (An intersection of convex sets is convex) If \(K_1\) and \(K_2\) are convex subsets of \(\mathbb{R}^p\) (Definition 1), then \(K_1 \cap K_2\) is convex.
Proof. Let \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}, \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}\in K_1 \cap K_2\) and \(t \in [0, 1]\). Then \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}, \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}\in K_1\), so \(t \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}+ (1 - t) \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}\in K_1\), since \(K_1\) is convex; in the same way \(t \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}+ (1 - t) \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}\in K_2\). So \(t \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}+ (1 - t) \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}\in K_1 \cap K_2\).
Example 4 (Intersecting a ball with a half-plane) The closed unit ball (unit ball) in \(\mathbb{R}^2\) is convex (Example 1), and so is the half-plane (Definition 2) \(\mathopen{}\left\{\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}: x_1 \ge 0\right\}\mathclose{}\): if \(x_1 \ge 0\) and \(y_1 \ge 0\), then \(t x_1 + (1 - t) y_1 \ge 0\) for \(t \in [0, 1]\). By Theorem 1, the closed half-disk \(\mathopen{}\left\{\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}: \mathopen{}\left\lVert\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}\right\rVert\mathclose{} \le 1,\ x_1 \ge 0\right\}\mathclose{}\) is convex. A union need not be convex: \(\mathopen{}\left\{x \in \mathbb{R}: x \le -1\right\}\mathclose{}\) and \(\mathopen{}\left\{x \in \mathbb{R}: x \ge 1\right\}\mathclose{}\) are convex, but their union is the set of Example 2.
Definition 3 (Strictly convex function) A function \(f : \mathbb{R}^p \to \mathbb{R}\) is strictly convex if \(f(t \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}+ (1 - t) \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}) < t f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}) + (1 - t) f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}})\) for all \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}\ne \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}\) in \(\mathbb{R}^p\) and all \(t \in (0, 1)\).
Definition 4 (Concave function) A function \(f : \mathbb{R}^p \to \mathbb{R}\) is concave if \(-f\) is convex.
Definition 5 (Strictly concave function) A function \(f : \mathbb{R}^p \to \mathbb{R}\) is strictly concave if \(-f\) is strictly convex (Definition 3).
Example 5 (Strictly convex, and convex but not strictly)
-
\(f(x) = x^2\) is strictly convex:
\[ \begin{aligned} t x^2 + (1 - t) y^2 - (t x + (1 - t) y)^2 &= t x^2 + (1 - t) y^2 - t^2 x^2 - 2 t (1 - t) x y - (1 - t)^2 y^2 && \text{(expand the square)} \\ &= t (1 - t) x^2 - 2 t (1 - t) x y + t (1 - t) y^2 && \text{(} t - t^2 = t (1 - t) \text{, } (1 - t) - (1 - t)^2 = t (1 - t) \text{)} \\ &= t (1 - t) (x - y)^2, && \text{(factor)} \end{aligned} \]
which is positive when \(x \ne y\) and \(t \in (0, 1)\). At \(t \in \mathopen{}\left\{0, 1\right\}\mathclose{}\) or \(x = y\) it is \(0\), so \(x^2\) is also convex.
-
\(f(x) = 2x + 1\) is convex but not strictly convex:
\[ \begin{aligned} f(t x + (1 - t) y) &= 2 t x + 2 (1 - t) y + 1 \\ &= t f(x) + (1 - t) f(y) \end{aligned} \]
for every \(x, y, t\), so the inequality holds, but never strictly. It is also concave.
Theorem 2 (The maximum of convex functions is convex) If \(f_1\) and \(f_2\) are convex functions on \(\mathbb{R}^p\), then \(f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}) \stackrel{\text{def}}{=}\max\mathopen{}\left\{f_1(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}), f_2(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}})\right\}\mathclose{}\) is convex.
Proof. Let \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}, \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}\in \mathbb{R}^p\) and \(t \in [0, 1]\). For \(i = 1, 2\),
\[ \begin{aligned} f_i(t \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}+ (1 - t) \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}) &\le t f_i(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}) + (1 - t) f_i(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}) && \text{(} f_i \text{ is convex)} \\ &\le t f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}) + (1 - t) f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}). && \text{(} f_i \le f \text{, and } t, 1 - t \ge 0 \text{)} \end{aligned} \]
Both \(f_1\) and \(f_2\) at \(t \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}+ (1 - t) \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}\) are at most \(t f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}) + (1 - t) f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}})\), so their maximum \(f(t \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}+ (1 - t) \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}})\) is too.
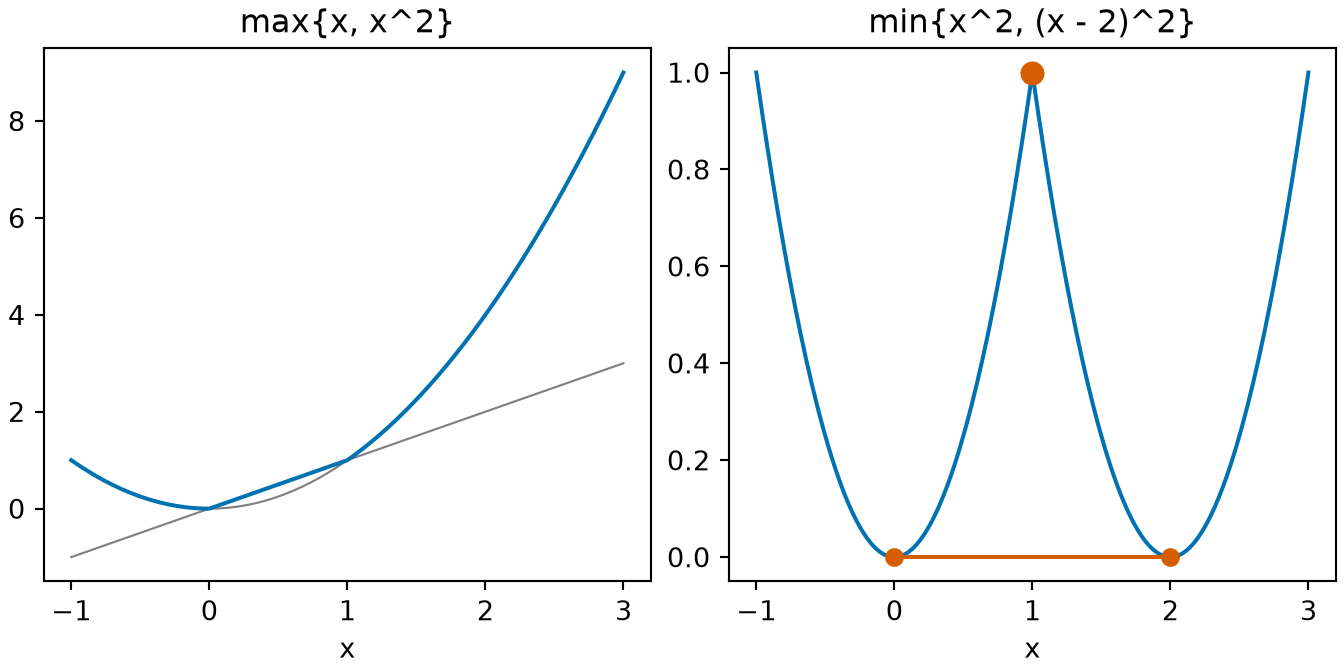
Example 6 (A maximum is convex; a minimum need not be)
\(f_1(x) = x\) is convex, by the computation for \(2x + 1\) in Example 5 with \(2\) and \(1\) replaced by \(1\) and \(0\), and \(f_2(x) = x^2\) is convex by the same example, so \(\max\mathopen{}\left\{x, x^2\right\}\mathclose{}\) is convex by Theorem 2.
-
The minimum of two convex functions need not be convex: \(g(x) = \min\mathopen{}\left\{x^2, (x - 2)^2\right\}\mathclose{}\) has
\[ \begin{aligned} g(0) &= g(2) \\ &= 0, \end{aligned} \]
but at the midpoint
\[ \begin{aligned} g(1) &= \min\mathopen{}\left\{1, 1\right\}\mathclose{} \\ &= 1 \\ &> \tfrac{1}{2} g(0) + \tfrac{1}{2} g(2) \\ &= 0. \end{aligned} \]
[Code]
cm_x_fm <- seq(-1, 3, length.out = 201)
cm_levels_fm <- c("max{x, x^2}", "min{x^2, (x - 2)^2}")
cm_max_value_fm <- pmax(cm_x_fm, cm_x_fm^2)
cm_min_value_fm <- pmin(cm_x_fm^2, (cm_x_fm - 2)^2)
cm_max_fm <- tibble::tibble(
  x = cm_x_fm, value = cm_max_value_fm, panel = cm_levels_fm[1]
)
cm_min_fm <- tibble::tibble(
  x = cm_x_fm, value = cm_min_value_fm, panel = cm_levels_fm[2]
)
cm_main_fm <- dplyr::bind_rows(cm_max_fm, cm_min_fm)
cm_main_fm$panel <- factor(cm_main_fm$panel, levels = cm_levels_fm)
cm_square_value_fm <- cm_x_fm^2
cm_line_fm <- tibble::tibble(
  x = cm_x_fm, value = cm_x_fm, panel = cm_levels_fm[1], part = "x"
)
cm_square_fm <- tibble::tibble(
  x = cm_x_fm, value = cm_square_value_fm, panel = cm_levels_fm[1],
  part = "x^2"
)
cm_parts_fm <- dplyr::bind_rows(cm_line_fm, cm_square_fm)
cm_parts_fm$panel <- factor(cm_parts_fm$panel, levels = cm_levels_fm)
cm_chord_fm <- tibble::tibble(
  x = 0, xend = 2, value = 0, panel = cm_levels_fm[2]
)
cm_chord_fm$panel <- factor(cm_chord_fm$panel, levels = cm_levels_fm)
cm_mid_fm <- tibble::tibble(x = 1, value = 1, panel = cm_levels_fm[2])
cm_mid_fm$panel <- factor(cm_mid_fm$panel, levels = cm_levels_fm)
cm_aes_fm <- ggplot2::aes(x, value)
cm_parts_aes_fm <- ggplot2::aes(group = part)
cm_chord_aes_fm <- ggplot2::aes(xend = xend, yend = value)
ggplot2::ggplot(cm_main_fm, cm_aes_fm) +
  ggplot2::geom_line(
    data = cm_parts_fm, mapping = cm_parts_aes_fm,
    colour = "grey60", linewidth = 0.4
  ) +
  ggplot2::geom_line(colour = "#0072B2") +
  ggplot2::geom_segment(
    data = cm_chord_fm, mapping = cm_chord_aes_fm, colour = "#D55E00"
  ) +
  ggplot2::geom_point(data = cm_mid_fm, colour = "#D55E00", size = 3) +
  ggplot2::facet_wrap(~panel, scales = "free_y") +
  ggplot2::labs(x = "x", y = NULL)
[Code]
import matplotlib.pyplot as plt
import numpy as np

cm_x_fm = np.linspace(-1, 3, 201)
fig, axes = plt.subplots(1, 2, figsize=(7, 3.5), layout="constrained")
axes[0].plot(cm_x_fm, cm_x_fm, color="grey", linewidth=0.8)
axes[0].plot(cm_x_fm, cm_x_fm**2, color="grey", linewidth=0.8)
axes[0].plot(cm_x_fm, np.maximum(cm_x_fm, cm_x_fm**2), color="#0072B2")
axes[0].set_title("max{x, x^2}")
axes[1].plot(cm_x_fm, np.minimum(cm_x_fm**2, (cm_x_fm - 2)**2), color="#0072B2")
axes[1].plot([0, 2], [0, 0], "o-", color="#D55E00", markersize=6)
axes[1].plot(1, 1, "o", color="#D55E00", markersize=8)
axes[1].set_title("min{x^2, (x - 2)^2}")
for ax in axes:
    ax.set_xlabel("x")
plt.show()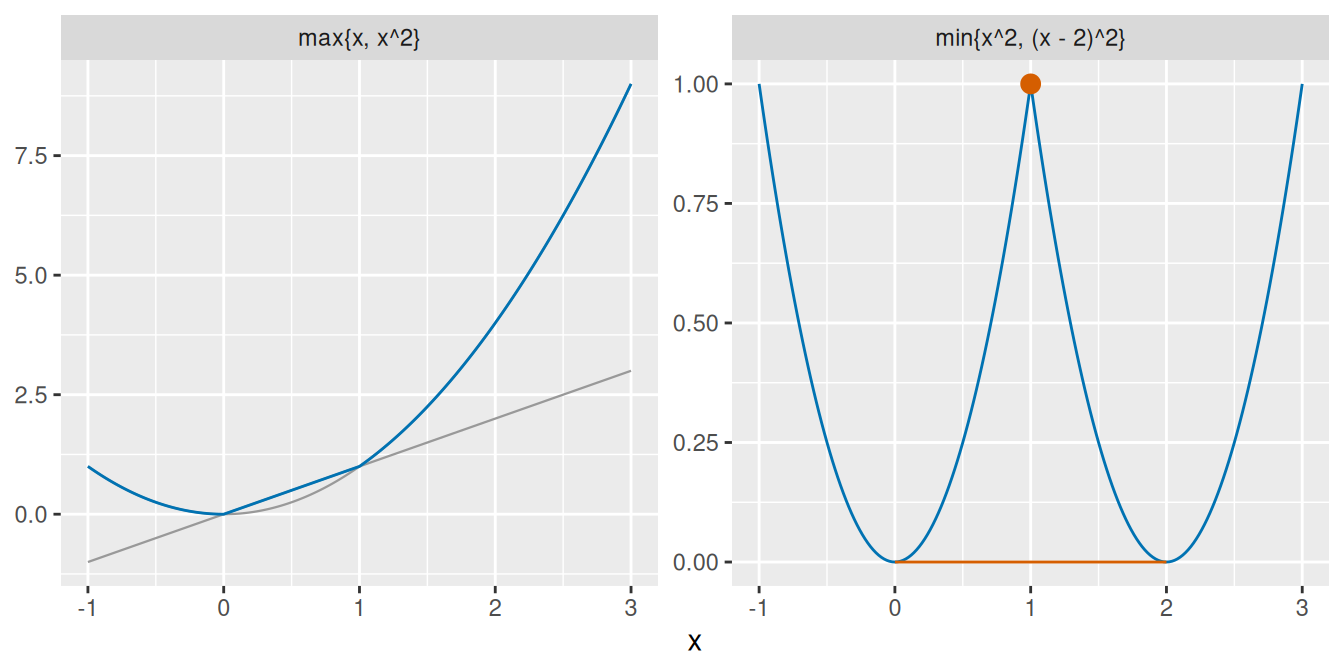
Definition 6 (Epigraph) The epigraph [3] of \(f : \mathbb{R}^p \to \mathbb{R}\) is the set of points on or over its graph,
\[ \operatorname{epi} f \stackrel{\text{def}}{=}\mathopen{}\left\{(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}, s) : \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}\in \mathbb{R}^p,\ s \in \mathbb{R},\ f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}) \le s\right\}\mathclose{}. \]
A pair \((\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}, s)\) is treated as the \((p + 1)\)-vector with entries \(x_1, \ldots, x_p, s\), so \(\operatorname{epi} f \subseteq \mathbb{R}^{p+1}\), and sums and multiples of pairs are taken entry by entry.
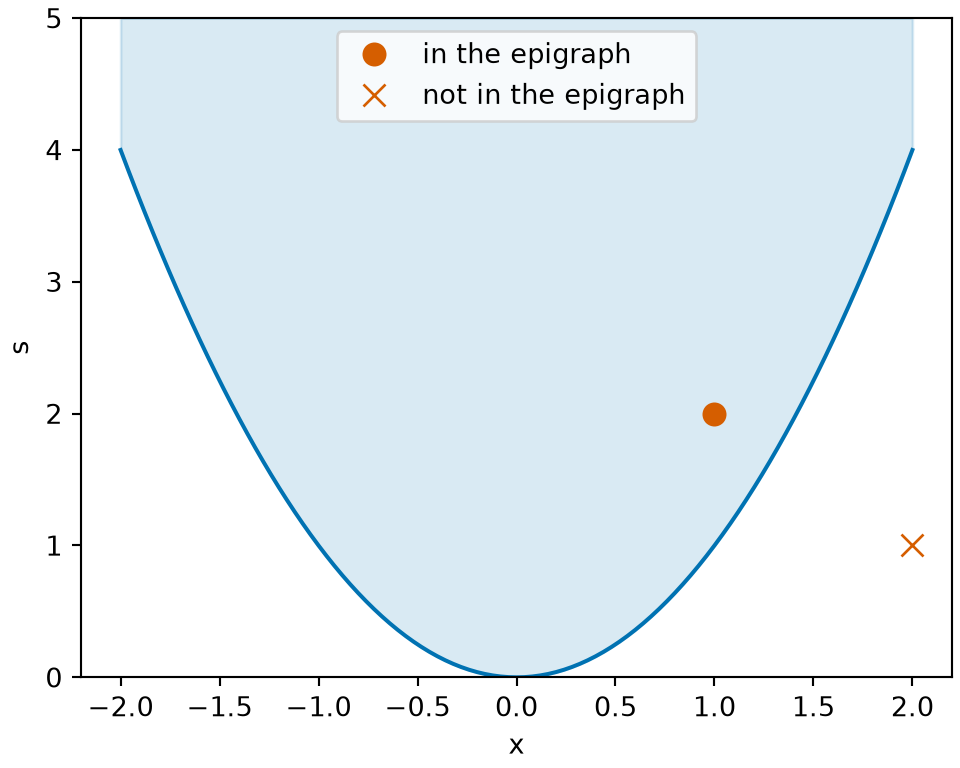
Example 7 (The epigraph of \(x^2\)) For \(f(x) = x^2\), \(\operatorname{epi} f = \mathopen{}\left\{(x, s) : x^2 \le s\right\}\mathclose{}\), the points \((x, s)\) on the parabola \(s = x^2\) or on the side of it where \(s\) is larger. \((1, 2)\) is in it, since \(1^2 \le 2\); \((2, 1)\) is not, since \(2^2 > 1\).
[Code]
ep_x_fe <- seq(-2, 2, length.out = 201)
ep_curve_fe <- tibble::tibble(x = ep_x_fe, s = ep_x_fe^2, top = 5)
ep_marks_x_fe <- c(1, 2)
ep_marks_s_fe <- c(2, 1)
ep_marks_kind_fe <- c("in the epigraph", "not in the epigraph")
ep_marks_fe <- tibble::tibble(
  x = ep_marks_x_fe, s = ep_marks_s_fe, kind = ep_marks_kind_fe
)
ep_aes_fe <- ggplot2::aes(x, s)
ep_ribbon_aes_fe <- ggplot2::aes(ymin = s, ymax = top)
ep_marks_aes_fe <- ggplot2::aes(shape = kind)
ep_shapes_fe <- c("in the epigraph" = 16, "not in the epigraph" = 4)
ggplot2::ggplot(ep_curve_fe, ep_aes_fe) +
  ggplot2::geom_ribbon(
    mapping = ep_ribbon_aes_fe, fill = "#0072B2", alpha = 0.15
  ) +
  ggplot2::geom_line(colour = "#0072B2") +
  ggplot2::geom_point(
    data = ep_marks_fe, mapping = ep_marks_aes_fe,
    colour = "#D55E00", size = 3
  ) +
  ggplot2::scale_shape_manual(values = ep_shapes_fe) +
  ggplot2::labs(x = "x", y = "s", shape = NULL)
[Code]
import matplotlib.pyplot as plt
import numpy as np

ep_x_fe = np.linspace(-2, 2, 201)
fig, ax = plt.subplots(figsize=(5, 4), layout="constrained")
ax.fill_between(ep_x_fe, ep_x_fe**2, 5, color="#0072B2", alpha=0.15)
ax.plot(ep_x_fe, ep_x_fe**2, color="#0072B2")
ax.plot(1, 2, "o", color="#D55E00", markersize=8, label="in the epigraph")
ax.plot(2, 1, "x", color="#D55E00", markersize=8, label="not in the epigraph")
ax.set_ylim(0, 5)
#> (0.0, 5.0)
ax.set_xlabel("x")
ax.set_ylabel("s")
ax.legend(loc="upper center")
plt.show()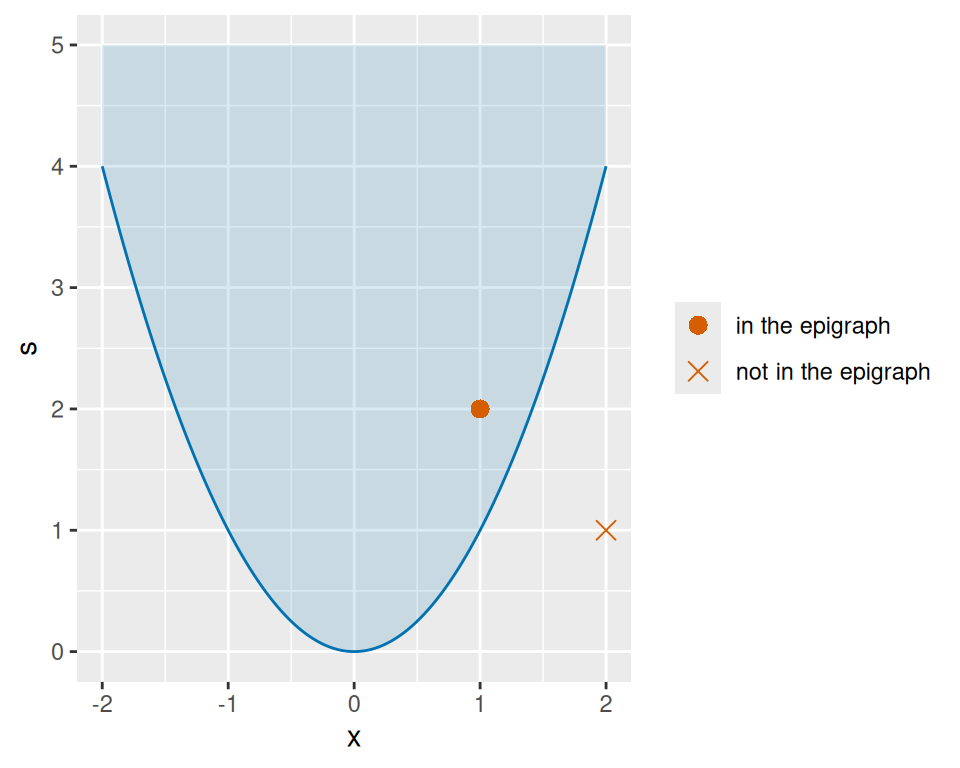
Theorem 3 (Convexity through the epigraph) \(f : \mathbb{R}^p \to \mathbb{R}\) is convex if and only if its epigraph (Definition 6) is convex (Definition 1).
Proof. If. Let \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}, \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}\in \mathbb{R}^p\) and \(t \in [0, 1]\). The points \((\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}, f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}))\) and \((\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}, f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}))\) are in \(\operatorname{epi} f\), since \(f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}) \le f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}})\) and \(f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}) \le f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}})\). Since \(\operatorname{epi} f\) is convex, it contains
\[ t\,(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}, f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}})) + (1 - t)\,(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}, f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}})) = \mathopen{}\left(t \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}+ (1 - t) \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}},\ t f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}) + (1 - t) f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}})\right)\mathclose{}, \]
and by Definition 6 that membership means \(f(t \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}+ (1 - t) \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}) \le t f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}) + (1 - t) f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}})\).
Only if. Let \((\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}, s)\) and \((\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}, u)\) be in \(\operatorname{epi} f\), so \(f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}) \le s\) and \(f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}) \le u\), and let \(t \in [0, 1]\). Then
\[ \begin{aligned} f(t \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}+ (1 - t) \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}) &\le t f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}) + (1 - t) f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}) && \text{(} f \text{ is convex)} \\ &\le t s + (1 - t) u, && \text{(} f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}) \le s \text{, } f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}) \le u \text{, and } t, 1 - t \ge 0 \text{)} \end{aligned} \]
so \(t\,(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}, s) + (1 - t)\,(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}, u) = (t \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}+ (1 - t) \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}},\ t s + (1 - t) u)\) is in \(\operatorname{epi} f\).
Example 8 (Two epigraphs)
- The epigraph of \(f(x) = \mathopen{}\left|x\right|\mathclose{}\) is \(\mathopen{}\left\{(x, s) : \mathopen{}\left|x\right|\mathclose{} \le s\right\}\mathclose{}\), a wedge. It is the intersection of the half-planes \(\mathopen{}\left\{(x, s) : s - x \ge 0\right\}\mathclose{}\) and \(\mathopen{}\left\{(x, s) : s + x \ge 0\right\}\mathclose{}\). Each half-plane is convex: if \(s_1 - x_1 \ge 0\) and \(s_2 - x_2 \ge 0\), then \((t s_1 + (1 - t) s_2) - (t x_1 + (1 - t) x_2) = t (s_1 - x_1) + (1 - t)(s_2 - x_2) \ge 0\), and the same with \(+\) for the other. So the wedge is convex (Theorem 1), and \(\mathopen{}\left|x\right|\mathclose{}\) is convex by Theorem 3.
- The epigraph of \(g(x) = -x^2\) is not convex: \((-1, -1)\) and \((1, -1)\) are in it, since \(g(\pm 1) = -1\), but their midpoint \((0, -1)\) is not, since \(g(0) = 0 > -1\). So \(-x^2\) is not convex.
Definition 7 (Tangent plane) Let \(f : \mathbb{R}^p \to \mathbb{R}\) have a gradient at \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}\) (gradient). The tangent plane [4] to the graph of \(f\) at \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}\) is the graph of the function
\[ \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}\mapsto f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}) + {\mathopen{}\left(\frac{\partial}{\partial \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}} f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}})\right)\mathclose{}}^{\top} (\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}- \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}), \]
which takes the value \(f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}})\) at \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}= \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}\) and has the same gradient as \(f\) there.
Example 9 (A tangent line and a tangent plane)
-
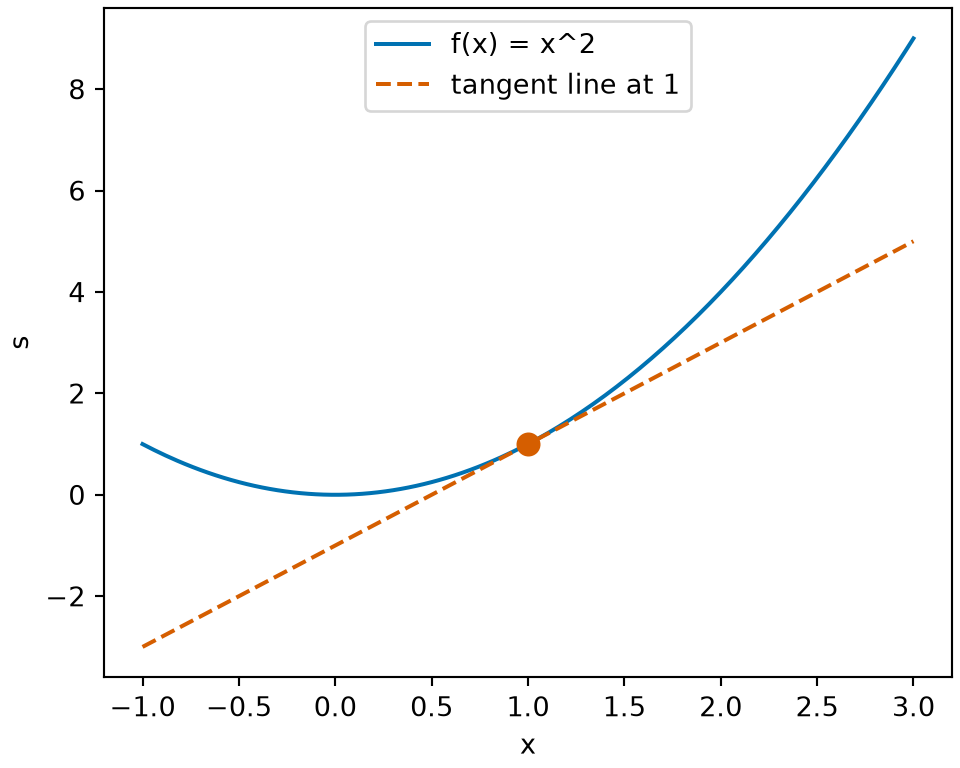
For \(f(x) = x^2\) at \(y = 1\), \(f(1) = 1\) and \(f'(1) = 2\), so the tangent line is
\[ \begin{aligned} s &= 1 + 2\,(x - 1) && \text{(substitute } f(1) \text{ and } f'(1) \text{)} \\ &= 1 + 2x - 2 && \text{(distribute)} \\ &= 2x - 1. && \text{(} 1 - 2 = -1 \text{)} \end{aligned} \]
-
For \(f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}) = x_1^2 + x_2^2\) at \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}= {(1, 1)}^{\top}\), \(f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}) = 2\) and the gradient is \({(2 y_1,\ 2 y_2)}^{\top} = {(2, 2)}^{\top}\), so the tangent plane is
\[ \begin{aligned} s &= 2 + 2\,(x_1 - 1) + 2\,(x_2 - 1) && \text{(substitute } f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}) \text{ and the gradient)} \\ &= 2 + 2 x_1 - 2 + 2 x_2 - 2 && \text{(distribute)} \\ &= 2 x_1 + 2 x_2 - 2. && \text{(} 2 - 2 - 2 = -2 \text{)} \end{aligned} \]
Remark 1 (The tangent plane in one variable). For \(p = 1\) the tangent plane is the tangent line \(s = f(y) + f'(y)\,(x - y)\), the line through \((y, f(y))\) with slope \(f'(y)\).
Theorem 4 (First-order characterization of convexity) Let \(f : \mathbb{R}^p \to \mathbb{R}\) have first partial derivatives that are continuous on \(\mathbb{R}^p\) (continuity). Then \(f\) is convex if and only if
\[ f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}) \ge f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}) + {\mathopen{}\left(\frac{\partial}{\partial \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}} f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}})\right)\mathclose{}}^{\top} (\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}- \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}) \qquad \text{for all } \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}, \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}\in \mathbb{R}^p: \tag{1}\]
every tangent plane (Definition 7) lies on or under the graph. If the inequality is strict whenever \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}\ne \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}\), then \(f\) is strictly convex (Definition 3).
Proof. Only if. Let \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}, \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}\in \mathbb{R}^p\), let \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{d}}\vphantom{d}} \stackrel{\text{def}}{=}\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}- \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}\), and let \(g(t) \stackrel{\text{def}}{=}f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}+ t \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{d}}\vphantom{d}})\). The inner function \(t \mapsto \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}+ t \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{d}}\vphantom{d}}\) has derivative \({\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{d}}\vphantom{d}}}^{\top}\) (vector-valued derivative), so the vector chain rule (vector chain rule) gives
\[ \begin{aligned} g'(0) &= {\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{d}}\vphantom{d}}}^{\top}\,\frac{\partial}{\partial \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}} f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}) && \text{(vector chain rule)} \\ &= {\mathopen{}\left(\frac{\partial}{\partial \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}} f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}})\right)\mathclose{}}^{\top} \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{d}}\vphantom{d}}. && \text{(a } 1 \times 1 \text{ matrix equals its transpose)} \end{aligned} \]
For \(t \in (0, 1]\), \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}+ t \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{d}}\vphantom{d}} = t \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}+ (1 - t) \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}\), so
\[ \begin{aligned} g(t) - g(0) &= f(t \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}+ (1 - t) \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}) - f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}) && \text{(definition of } g \text{)} \\ &\le t f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}) + (1 - t) f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}) - f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}) && \text{(} f \text{ is convex)} \\ &= t\,(f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}) - f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}})), && \text{(collect terms)} \end{aligned} \]
and dividing by \(t > 0\), \(\dfrac{g(t) - g(0)}{t} \le f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}) - f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}})\). As \(t \to 0\) from the right, the left side tends to \(g'(0)\) (\(g\) is differentiable at \(0\), so the one-sided limit equals the two-sided derivative), and a limit of numbers that are all at most \(f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}) - f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}})\) is at most \(f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}) - f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}})\). So \({\mathopen{}\left(\frac{\partial}{\partial \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}} f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}})\right)\mathclose{}}^{\top} (\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}- \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}) \le f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}) - f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}})\), which rearranges to Equation 1.
If. Let \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}, \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}\in \mathbb{R}^p\), \(t \in [0, 1]\), \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{z}}\vphantom{z}} \stackrel{\text{def}}{=}t \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}+ (1 - t) \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}\), and \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{g}}\vphantom{g}} \stackrel{\text{def}}{=}\frac{\partial}{\partial \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}} f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{z}}\vphantom{z}})\). Applying Equation 1 at the point \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{z}}\vphantom{z}}\), once toward \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}\) and once toward \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}\),
\[ f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}) \ge f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{z}}\vphantom{z}}) + {\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{g}}\vphantom{g}}}^{\top} (\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}- \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{z}}\vphantom{z}}), \qquad f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}) \ge f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{z}}\vphantom{z}}) + {\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{g}}\vphantom{g}}}^{\top} (\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}- \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{z}}\vphantom{z}}). \]
Multiplying the first by \(t \ge 0\) and the second by \(1 - t \ge 0\) and adding,
\[ \begin{aligned} t f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}) + (1 - t) f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}) &\ge t \mathopen{}\left(f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{z}}\vphantom{z}}) + {\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{g}}\vphantom{g}}}^{\top} (\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}- \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{z}}\vphantom{z}})\right)\mathclose{} + (1 - t) \mathopen{}\left(f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{z}}\vphantom{z}}) + {\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{g}}\vphantom{g}}}^{\top} (\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}- \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{z}}\vphantom{z}})\right)\mathclose{} && \text{(multiply by } t, 1 - t \ge 0 \text{ and add)} \\ &= (t + (1 - t))\,f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{z}}\vphantom{z}}) + t\,{\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{g}}\vphantom{g}}}^{\top} (\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}- \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{z}}\vphantom{z}}) + (1 - t)\,{\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{g}}\vphantom{g}}}^{\top} (\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}- \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{z}}\vphantom{z}}) && \text{(distribute } t \text{ and } 1 - t \text{)} \\ &= f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{z}}\vphantom{z}}) + t\,{\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{g}}\vphantom{g}}}^{\top} (\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}- \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{z}}\vphantom{z}}) + (1 - t)\,{\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{g}}\vphantom{g}}}^{\top} (\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}- \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{z}}\vphantom{z}}) && \text{(} t + (1 - t) = 1 \text{)} \\ &= f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{z}}\vphantom{z}}) + {\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{g}}\vphantom{g}}}^{\top} \mathopen{}\left(t (\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}- \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{z}}\vphantom{z}}) + (1 - t) (\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}- \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{z}}\vphantom{z}})\right)\mathclose{} && \text{(factor out } {\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{g}}\vphantom{g}}}^{\top} \text{; matrix products distribute)} \\ &= f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{z}}\vphantom{z}}) + {\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{g}}\vphantom{g}}}^{\top} \mathopen{}\left(t \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}+ (1 - t) \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}- \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{z}}\vphantom{z}}\right)\mathclose{} && \text{(collect terms)} \\ &= f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{z}}\vphantom{z}}). && \text{(definition of } \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{z}}\vphantom{z}} \text{)} \end{aligned} \]
That inequality is the defining inequality of a convex function. If Equation 1 is strict for distinct points, and \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}\ne \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}\) and \(t \in (0, 1)\), then:
- \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{z}}\vphantom{z}}\) differs from both \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}\) and \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}\), since \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}- \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{z}}\vphantom{z}} = (1 - t)(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}- \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}) \ne \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{0}}\vphantom{0}}\) and \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}- \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{z}}\vphantom{z}} = t (\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}- \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}) \ne \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{0}}\vphantom{0}}\);
- so both inequalities at \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{z}}\vphantom{z}}\) are strict;
- both multipliers \(t\) and \(1 - t\) are positive, so the first step of the display is strict, and \(f\) is strictly convex.
Example 10 (Tangent lines under a parabola) For \(f(x) = x^2\), the right side of Equation 1 is \(y^2 + 2y (x - y) = 2xy - y^2\), and
\[ \begin{aligned} f(x) - (2xy - y^2) &= x^2 - 2xy + y^2 \\ &= (x - y)^2 \\ &\ge 0, \end{aligned} \]
with equality only at \(x = y\), confirming that \(x^2\) is strictly convex. For \(g(x) = -x^2\) the inequality fails: at \(y = 0\) the tangent line is \(s = 0\), and \(g(1) = -1 < 0\).
[Code]
tl_x_ft <- seq(-1, 3, length.out = 201)
tl_curve_ft <- tibble::tibble(x = tl_x_ft, s = tl_x_ft^2)
tl_line_ft <- tibble::tibble(x = tl_x_ft, s = 2 * tl_x_ft - 1)
tl_point_ft <- tibble::tibble(x = 1, s = 1)
tl_aes_ft <- ggplot2::aes(x, s)
ggplot2::ggplot(tl_curve_ft, tl_aes_ft) +
  ggplot2::geom_line(colour = "#0072B2") +
  ggplot2::geom_line(
    data = tl_line_ft, colour = "#D55E00", linetype = "dashed"
  ) +
  ggplot2::geom_point(data = tl_point_ft, colour = "#D55E00", size = 3) +
  ggplot2::labs(x = "x", y = "s")
[Code]
import matplotlib.pyplot as plt
import numpy as np

tl_x_ft = np.linspace(-1, 3, 201)
fig, ax = plt.subplots(figsize=(5, 4), layout="constrained")
ax.plot(tl_x_ft, tl_x_ft**2, color="#0072B2", label="f(x) = x^2")
ax.plot(tl_x_ft, 2 * tl_x_ft - 1, "--", color="#D55E00",
        label="tangent line at 1")
ax.plot(1, 1, "o", color="#D55E00", markersize=8)
ax.set_xlabel("x")
ax.set_ylabel("s")
ax.legend(loc="upper center")
plt.show()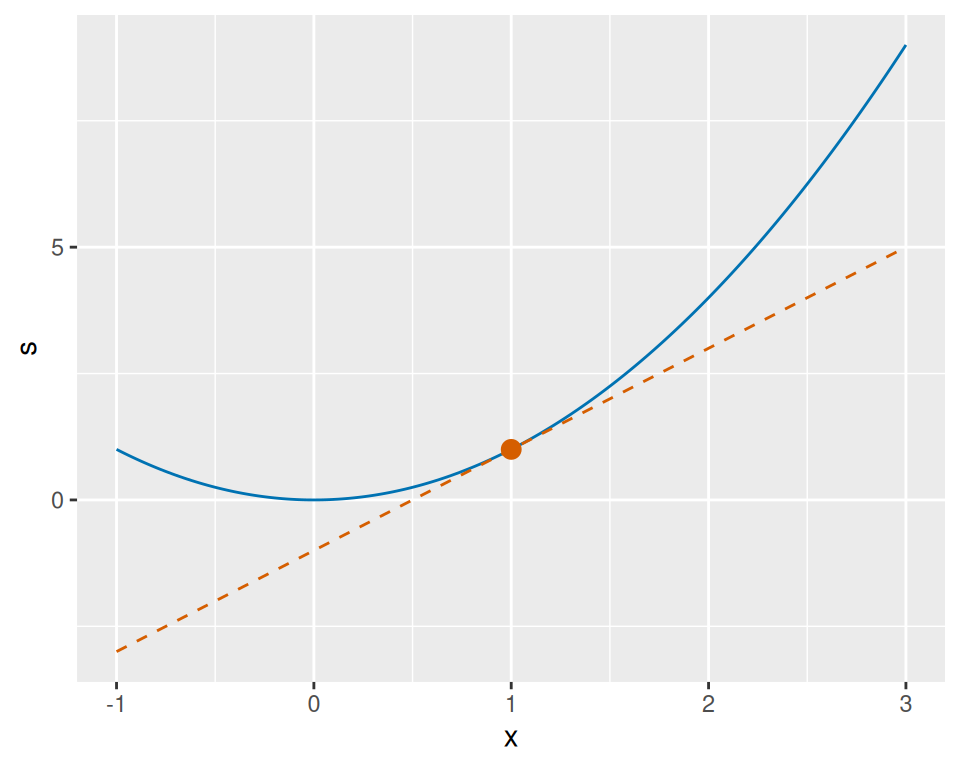
Theorem 5 (Second-derivative test for convexity) Let \(f : \mathbb{R}^p \to \mathbb{R}\) have first and second partial derivatives that are continuous on \(\mathbb{R}^p\) (continuity).
- If \(\mathbf{H}_f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}})\) is positive semidefinite for every \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}\), then \(f\) is convex.
- If \(\mathbf{H}_f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}})\) is positive definite for every \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}\), then \(f\) is strictly convex (Definition 3).
Proof. Let \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}, \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}\in \mathbb{R}^p\). By Theorem 6 in Critical Points and Optimality Conditions with \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{z}}\vphantom{z}} = \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}\) and \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{h}}\vphantom{h}} = \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}- \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}\), there is a \(\tau\in (0, 1)\) such that, with \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{w}}\vphantom{w}} \stackrel{\text{def}}{=}\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}+ \tau(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}- \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}})\),
\[ \begin{aligned} f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}) &= f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}) + {\mathopen{}\left(\frac{\partial}{\partial \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}} f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}})\right)\mathclose{}}^{\top} (\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}- \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}) + \frac{1}{2}\,{(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}- \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}})}^{\top}\,\mathbf{H}_f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{w}}\vphantom{w}})\,(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}- \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}) && \text{(}\href{optimization-critical-points.qmd#thm-taylor-mv}{\text{Theorem~6 in Critical Points and Optimality Conditions}}\text{)} \\ &\ge f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}) + {\mathopen{}\left(\frac{\partial}{\partial \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}} f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}})\right)\mathclose{}}^{\top} (\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}- \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}). && \text{(} \mathbf{H}_f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{w}}\vphantom{w}}) \text{ is positive semidefinite)} \end{aligned} \]
This inequality is Equation 1, so \(f\) is convex by Theorem 4. Under the hypothesis of part 2 and with \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}\ne \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}\), the quadratic-form term is positive, so the inequality is strict, and \(f\) is strictly convex by the last sentence of Theorem 4.
Example 11 (Using the Hessian to show convexity)
For a symmetric positive semidefinite \(\mathbf{A}\), \(f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}) = {\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}}^{\top} \mathbf{A} \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}\) has Hessian \(2 \mathbf{A}\) (Hessian of a quadratic form), which is positive semidefinite because \({\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{h}}\vphantom{h}}}^{\top} (2 \mathbf{A}) \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{h}}\vphantom{h}} = 2\,{\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{h}}\vphantom{h}}}^{\top} \mathbf{A} \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{h}}\vphantom{h}} \ge 0\); so \(f\) is convex.
\(f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}) = x_1^2 + x_2^2 - 2 x_1\) has Hessian \(2 \mathbf{I}_2\) (Example 15 in Critical Points and Optimality Conditions), which is positive definite, so \(f\) is strictly convex.
-
\(f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}) = e^{2x_1 + x_2} - x_1\) has Hessian \(e^{u} \begin{bmatrix} 4 & 2 \\ 2 & 1 \end{bmatrix}\) with \(u = 2x_1 + x_2\) (Example), and
\[ \begin{aligned} {\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{h}}\vphantom{h}}}^{\top}\,\mathbf{H}_f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}})\,\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{h}}\vphantom{h}} &= e^{u} (4 h_1^2 + 4 h_1 h_2 + h_2^2) \\ &= e^{u} (2 h_1 + h_2)^2 \\ &\ge 0, \end{aligned} \]
so \(f\) is convex. The Hessian is not positive definite (\(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{h}}\vphantom{h}} = {(1, -2)}^{\top}\) gives \(0\)), so part 2 does not apply, and in fact \(f\) is not strictly convex: along \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}= t\,{(1, -2)}^{\top}\),
\[ \begin{aligned} u &= 2t - 2t \\ &= 0 \end{aligned} \]
and \(f = 1 - t\) is linear in \(t\), so the convexity inequality holds with equality there.
Example 12 (Strictly convex with a singular Hessian) Part 2 is sufficient but not necessary. \(f(x) = x^4\) has
\[ \begin{aligned} f''(0) &= 12 \cdot 0^2 \\ &= 0, \end{aligned} \]
so \(\mathbf{H}_f(0) = [0]\) is singular and not positive definite. Yet \(f\) is strictly convex, by the strict form of Equation 1: for \(x \ne y\),
\[ \begin{aligned} x^4 - y^4 - 4 y^3 (x - y) &= (x - y)(x^3 + x^2 y + x y^2 + y^3) - 4 y^3 (x - y) && \text{(factor } x^4 - y^4 \text{)} \\ &= (x - y)(x^3 + x^2 y + x y^2 - 3 y^3) && \text{(collect the } y^3 \text{ terms)} \\ &= (x - y)^2 (x^2 + 2 x y + 3 y^2) && \text{(} (x - y)(x^2 + 2 x y + 3 y^2) = x^3 + x^2 y + x y^2 - 3 y^3 \text{)} \\ &= (x - y)^2 \mathopen{}\left((x + y)^2 + 2 y^2\right)\mathclose{}, && \text{(complete the square)} \end{aligned} \]
which is positive: \((x - y)^2 > 0\), and \((x + y)^2 + 2 y^2 = 0\) would need \(y = 0\) and then
\[ \begin{aligned} x &= 0 \\ &= y. \end{aligned} \]
Theorem 6 (A convex function has a positive semidefinite Hessian) Let \(f : \mathbb{R}^p \to \mathbb{R}\) have first and second partial derivatives that are continuous on \(\mathbb{R}^p\). If \(f\) is convex, then the Hessian \(\mathbf{H}_f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}})\) is positive semidefinite for every \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}\in \mathbb{R}^p\).
Proof. Fix \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}, \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{v}}\vphantom{v}} \in \mathbb{R}^p\). Let \(h > 0\). By Theorem 6 in Critical Points and Optimality Conditions applied with \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{z}}\vphantom{z}} = \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}\) and \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{h}}\vphantom{h}} = h\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{v}}\vphantom{v}}\), and again with \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{h}}\vphantom{h}} = -h\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{v}}\vphantom{v}}\), there are \(\tau_+, \tau_- \in (0, 1)\) with
\[ \begin{aligned} f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}+ h\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{v}}\vphantom{v}}) &= f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}) + h\,{\mathopen{}\left(\frac{\partial}{\partial \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}} f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}})\right)\mathclose{}}^{\top} \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{v}}\vphantom{v}} + \frac{h^2}{2}\,{\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{v}}\vphantom{v}}}^{\top}\,\mathbf{H}_f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{w}}\vphantom{w}}_+)\,\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{v}}\vphantom{v}} && \text{(}\href{optimization-critical-points.qmd#thm-taylor-mv}{\text{Theorem~6 in Critical Points and Optimality Conditions}}\text{)} \\ f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}- h\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{v}}\vphantom{v}}) &= f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}) - h\,{\mathopen{}\left(\frac{\partial}{\partial \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}} f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}})\right)\mathclose{}}^{\top} \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{v}}\vphantom{v}} + \frac{h^2}{2}\,{\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{v}}\vphantom{v}}}^{\top}\,\mathbf{H}_f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{w}}\vphantom{w}}_-)\,\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{v}}\vphantom{v}}, && \text{(}\href{optimization-critical-points.qmd#thm-taylor-mv}{\text{Theorem~6 in Critical Points and Optimality Conditions}}\text{)} \end{aligned} \]
where \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{w}}\vphantom{w}}_\pm = \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}\pm \tau_\pm h\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{v}}\vphantom{v}}\). Adding the two equations cancels the first-order summands:
\[ f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}+ h\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{v}}\vphantom{v}}) + f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}- h\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{v}}\vphantom{v}}) - 2 f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}) = \frac{h^2}{2}\,{\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{v}}\vphantom{v}}}^{\top}\mathopen{}\left(\mathbf{H}_f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{w}}\vphantom{w}}_+) + \mathbf{H}_f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{w}}\vphantom{w}}_-)\right)\mathclose{}\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{v}}\vphantom{v}}. \]
Since \(f\) is convex and \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}= \frac{1}{2}(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}+ h\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{v}}\vphantom{v}}) + \frac{1}{2}(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}- h\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{v}}\vphantom{v}})\),
\[ f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}) \le \frac{1}{2} f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}+ h\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{v}}\vphantom{v}}) + \frac{1}{2} f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}- h\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{v}}\vphantom{v}}), \]
so the left side of the previous display is nonnegative. Dividing by \(h^2 / 2\) gives
\[ {\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{v}}\vphantom{v}}}^{\top}\mathopen{}\left(\mathbf{H}_f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{w}}\vphantom{w}}_+) + \mathbf{H}_f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{w}}\vphantom{w}}_-)\right)\mathclose{}\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{v}}\vphantom{v}} \ge 0 \qquad \text{for every } h > 0. \]
As \(h \to 0\), both \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{w}}\vphantom{w}}_+\) and \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{w}}\vphantom{w}}_-\) approach \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}\), and the entries of \(\mathbf{H}_f\) are continuous, so the left side approaches \(2\,{\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{v}}\vphantom{v}}}^{\top}\,\mathbf{H}_f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}})\,\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{v}}\vphantom{v}}\). Therefore \({\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{v}}\vphantom{v}}}^{\top}\,\mathbf{H}_f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}})\,\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{v}}\vphantom{v}} \ge 0\) for every \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{v}}\vphantom{v}}\).
Corollary 1 (Stationary points of a convex function are global minimizers) If \(f\) is as in Theorem 4 and convex, then every stationary point \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}^*\) of \(f\) (Definition 4 in Critical Points and Optimality Conditions) is a global minimizer.
Proof. For every \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}\),
\[ \begin{aligned} f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}) &\ge f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}^*) + {\mathopen{}\left(\frac{\partial}{\partial \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}} f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}^*)\right)\mathclose{}}^{\top} (\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}- \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}^*) && \text{(}\href{#eq-supporting-hyperplane}{\text{Equation~1}}\text{ with } \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{y}}\vphantom{y}}= \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}^* \text{)} \\ &= f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}^*) + {\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{0}}\vphantom{0}}}^{\top} (\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}- \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}^*) && \text{(} \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}^* \text{ is stationary)} \\ &= f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}^*). && \text{(} \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{0}}\vphantom{0}} \cdot \mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{v}}\vphantom{v}} = 0 \text{)} \end{aligned} \]
Example 13 (A convex function, and a non-convex one)
- \(f(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{x}}\vphantom{x}}) = x_1^2 + x_2^2 - 2 x_1\) is convex by Theorem 5, since its Hessian is \(2 \mathbf{I}_2\) (Example 15 in Critical Points and Optimality Conditions), so its stationary point \({(1, 0)}^{\top}\) (Example 7 in Critical Points and Optimality Conditions) is a global minimizer, as completing the square showed in Example 8 in Critical Points and Optimality Conditions.
- Without convexity, a stationary point need not be a minimizer at all: \(x_1^2 - x_2^2\) has the stationary point \(\mathord{\smash[b]{\underset{\raise.3ex\hbox{$\scriptstyle\sim$}}{0}}\vphantom{0}}\), which is not a minimizer (Example 8 in Critical Points and Optimality Conditions).
- The corollary says nothing about whether a minimizer exists: \(e^{2x_1 + x_2} - x_1\) is convex (Example 11) but has no stationary point, and so no local minimizer (Example 8 in Critical Points and Optimality Conditions).
[1]
H. Zhou, “Optimization and multivariate calculus.” Lecture notes for Biostat 216, Mathematical Methods for Biostatistics, University of California, Los Angeles, 2024. Accessed: Oct. 05, 2026. [Online]. Available: https://ucla-biostat-216.github.io/2024fall/slides/13-optim/13-optim.html
[2]
Wikipedia contributors, “Convex set — Wikipedia, the free encyclopedia.” 2026. Available: https://en.wikipedia.org/wiki/Convex_set
[3]
Wikipedia contributors, “Epigraph (mathematics) — Wikipedia, the free encyclopedia.” 2026. Available: https://en.wikipedia.org/wiki/Epigraph_(mathematics)
[4]
Wikipedia contributors, “Tangent space — Wikipedia, the free encyclopedia.” 2026. Available: https://en.wikipedia.org/wiki/Tangent_space